2.1 Ratings and Specifications
2.1.1 Ratings
■ 1-phase 220VAC / 3-phase 220VAC
◆ SC303AAD▯▯ / SC306AAF▯▯ / SC308AAG▯▯ / SC310AAH▯▯
|
Model |
03A |
06A |
08A |
10A |
||
|
Continuous Output Current [Amps] |
3 |
6 |
8 |
10 |
||
|
Instan. Max. Output Current [Amps] |
10 |
14 |
21 |
23 |
||
|
Main Circuit |
Power Supply |
1-phase / 3-phase |
3-phase AC 220V,-15% ~ +10%, 50 Hz / 60 Hz*1 |
|||
|
Input Current [Amps] |
1.9 |
3.9 |
5.4 |
6.3 |
||
|
Control Power Supply |
1-phase AC 220V,-15% ~ +10%, 50 Hz / 60 Hz |
|||||
|
Power Supply Capacity [kVA] |
1.3 |
1.7 |
2.4 |
2.8 |
||
|
Regenertative Resistor |
Bulit-in |
Resistance [Ω] |
-*2 |
40 |
40 |
40 |
|
Capacity [W] |
– |
80 |
80 |
80 |
||
|
Min. Allowable External Resistance [Ω] |
30 |
15 |
12 |
12 |
||
|
Overvoltage Category |
Ⅲ |
|||||
*1: If use 1-phase AC220V for power supply, the current output may not meet the spec. *2: 03A servo driver have no bulit-in regenerative resistor.
■ 3-phase380VAC
◆ SC303ADE▯▯ / SC306ADH▯▯ / SC310ADI▯▯ / SC315ADK▯▯ / SC328ABL▯▯
|
Model |
03A |
06 |
10A |
15A |
28A |
|||
|
Continuous Output Current [Amps] |
3 |
6 |
10 |
15 |
28 |
|||
|
Instan. Max. Output Current [Amps] |
8.5 |
14 |
45 |
45 |
63 |
|||
|
Main Circuit |
Power Supply |
3-phase AC 380V,-15% ~ +10%, |
||||||
|
Input Current [Amps] |
3 |
5.9 |
9.7 |
15.5 |
24.8 |
|||
|
Control Power Supply |
DC 24V,-10% ~ +10%, 50W |
1-phase AC 380V,-15% ~+10%, |
||||||
|
Power Supply Capacity [kVA] |
2.0 |
3.9 |
7.8 |
12.4 |
19.8 |
|||
|
Regenertative Resistor |
Bulit-in |
Resistance [Ω] |
40 |
40 |
40 |
32 |
-*1 |
|
|
Capacity [W] |
80 |
80 |
40 |
150 |
– |
|||
|
Min. Allowable External Resistance [Ω] |
30 |
30 |
30 |
20 |
15 |
|||
|
Overvoltage Category |
Ⅲ |
|||||||
*1: 28A servo driver have no bulit-in regenerative resistor.
2.1.2 Specifications
|
Item |
Specification |
|
|
Control Method |
Position mode、JOG mode、speed mode…etc |
|
|
Feedback |
Serial encoder:17bits or 23bits(incremental encoder / absolute encoder) |
|
|
Environment Conditions |
Operation Temp. |
0~+50℃ |
|
Storage Temp. |
-20~+85℃ |
|
|
Environment Humidity |
90% relative humidity max. (with no freezing or condensation) |
|
|
Storage Humidity |
90% relative humidity max. (with no freezing or condensation) |
|
|
Vibration Resistance |
4.9m/s2 |
|
|
Shock Resistance |
19.6m/s2 |
|
|
Mounting |
Base-mounted |
|
|
Performance |
Speed Control Range |
1:10000(At the rated torque, the lower limit of the speed control range must not cause the Servomotor to stop.) |
|
Speed Response Freq. |
3.1KHz |
|
|
Coefficient of Speed Flucuation |
±0.01% of rated speed max. (for a load fluctuation of 0% to 100%) |
|
|
0% of rated speed max. (for a voltage fluctuation of ±10%) |
||
|
±0.1% of rated speed max. (for a temperature fluctuation of 25°C±25°C) |
||
|
Speed Control |
Reference Voltage |
DC±10V |
|
Input Impedance |
Approx. 20KΩ |
|
|
Circuit Time Constant |
47us |
|
|
Torque Control |
Reference Voltage |
DC±10V |
|
Input Impedance |
Approx. 20KΩ |
|
|
Circuit Time Constant |
47us |
|
|
Digital Input |
Number of points |
8 |
|
Input Signals That Can Be Allocated |
Servo ON(/S-ON)*1、Proportional Control(/P-CON)*1、Forward Drive Prohibit(P-OT)、Reverse Drive Prohibit(N-OT)、Alarm Reset(/ALM-RST)、Forward External Torque Limit(/P-CL)、Reverse External Torque Limit(/N-CL)、Position Deviation Clear(/CLR)、Internal Setup Speed Switch…etc |
|
|
Digital Output |
Number of points |
6 |
|
Output Signals That Can Be Allocated |
Servo Alarm(ALM)、Position Completion(/COIN)、Speed Coincidence Detection(/V-CMP)、Rotation Detection(/TGON)、Servo Ready(/S-RDY)、Torque Limit Detection(/CLT)、Brake(/BK)、Encoder Origin Output(PGC) A Signal can be allocated and positive and negative logic can be changed. |
|
|
Encoder Divided Pulse Output |
Phase A, phase B, phase Z: Line-driver output |
|
|
RS-485 *1 |
Protocal |
MODBUS |
|
1:N Communications |
Up to N=127 stations |
|
|
Axis Address Setting |
Set with parameters |
|
|
EtherCAT |
Protocal |
CoE (CANOpen over EtherCAT) |
|
Control Mode |
csp, pp, hm, csv, cst, pv, tq |
|
|
Homing Method |
1-14, 17-30, 33, 34, 35, 37 |
|
|
Synchronization Mode |
DC, SM2, FreeRun |
|
|
Cycle Time |
125us |
|
|
Displays/Indicators |
CHARGE indicator and five-digit seven-digit display |
|
|
Regenerative Processing |
Built-in (An external resistor must be connected to 220V_03A & 380V_28A) |
|
|
Overtravel(OT)Prevention |
Stopping with dynamic brake (DB), deceleration to a stop, or coasting to a stop for the P-OT (Forward Drive Prohibit) or N-OT (Reverse Drive Prohibit) signal |
|
|
Protective Function |
Overcurrent, overvoltage, low voltage, overload, regeneration error, etc. |
|
|
Monitoring Functions |
Speed, Current position, Reference pulse count (accumulated), Position deviation, Motor current, Operating status, Input/output signals |
|
|
Utility Functions |
Gain adjustment, alarm history, jogging, origin search, etc. |
|
|
Intelligent Functions |
Bulit-in Auto-tuning function |
|
|
Applicable Load Inertia |
Less than 5 times the motor inertia |
|
|
Position |
Feedforward Compensation |
0~100%(Setup Unit1%) |
|
Reference Pulse Form |
One of the following is selected: |
|
|
Input Form |
Line driver or open-collector |
|
|
Max. Input Frequency |
•Line Driver |
|
*1: Only support pulse type model
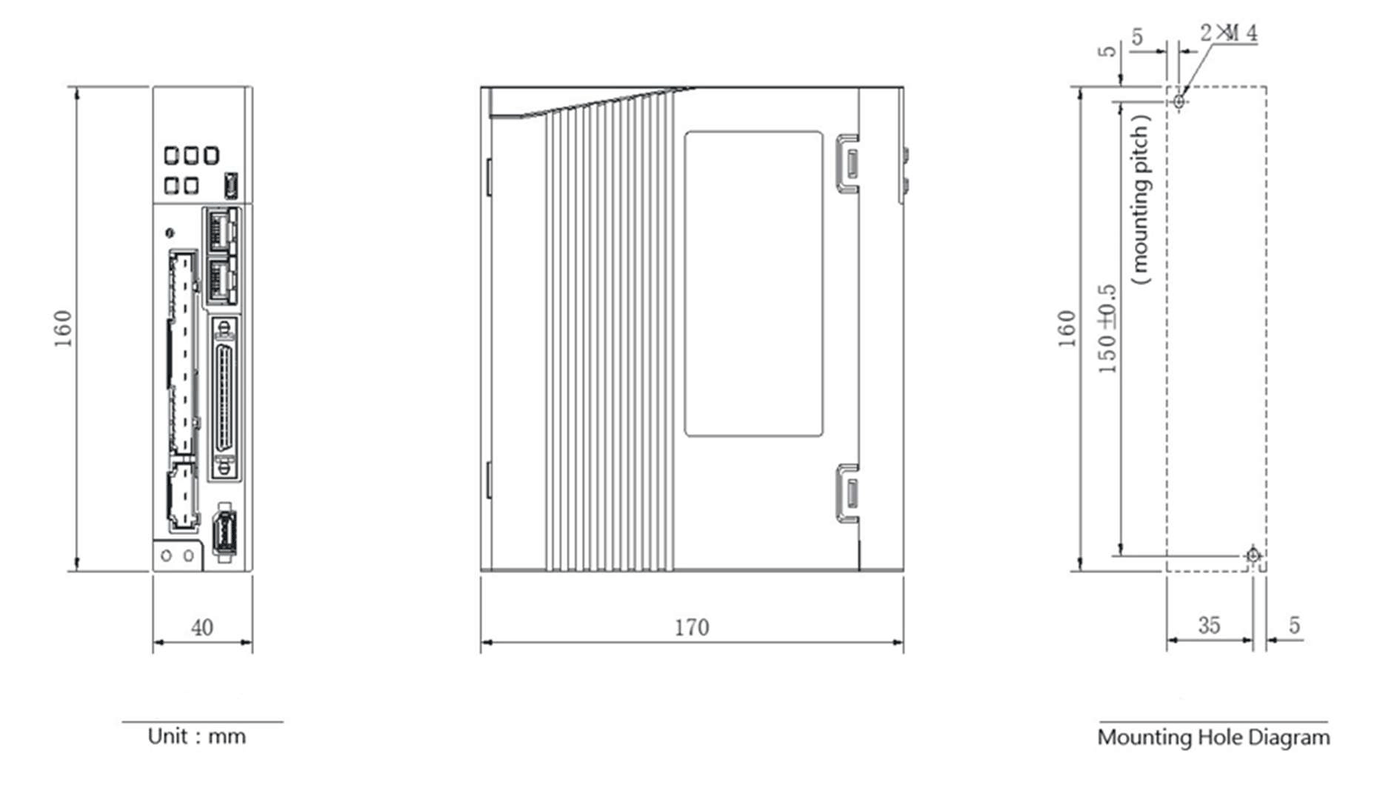
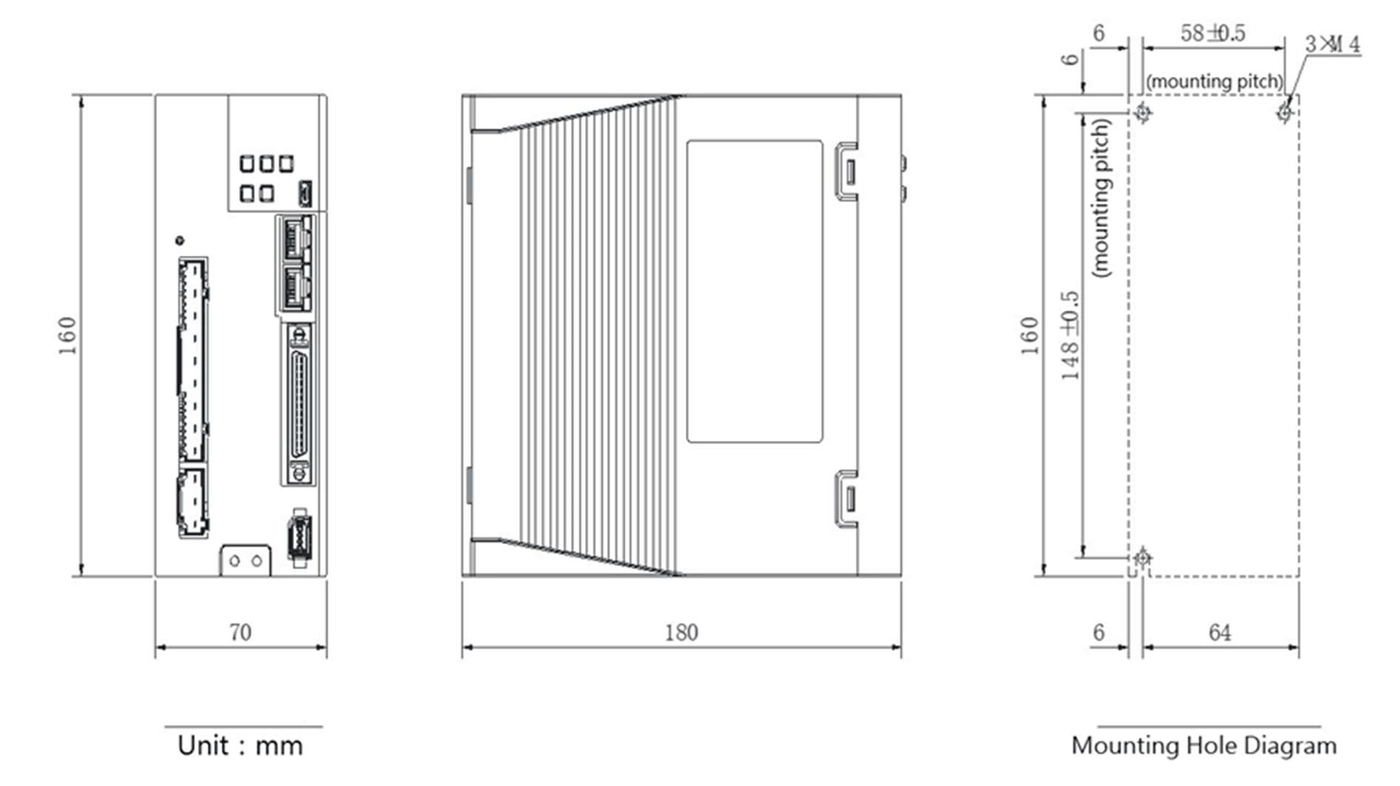
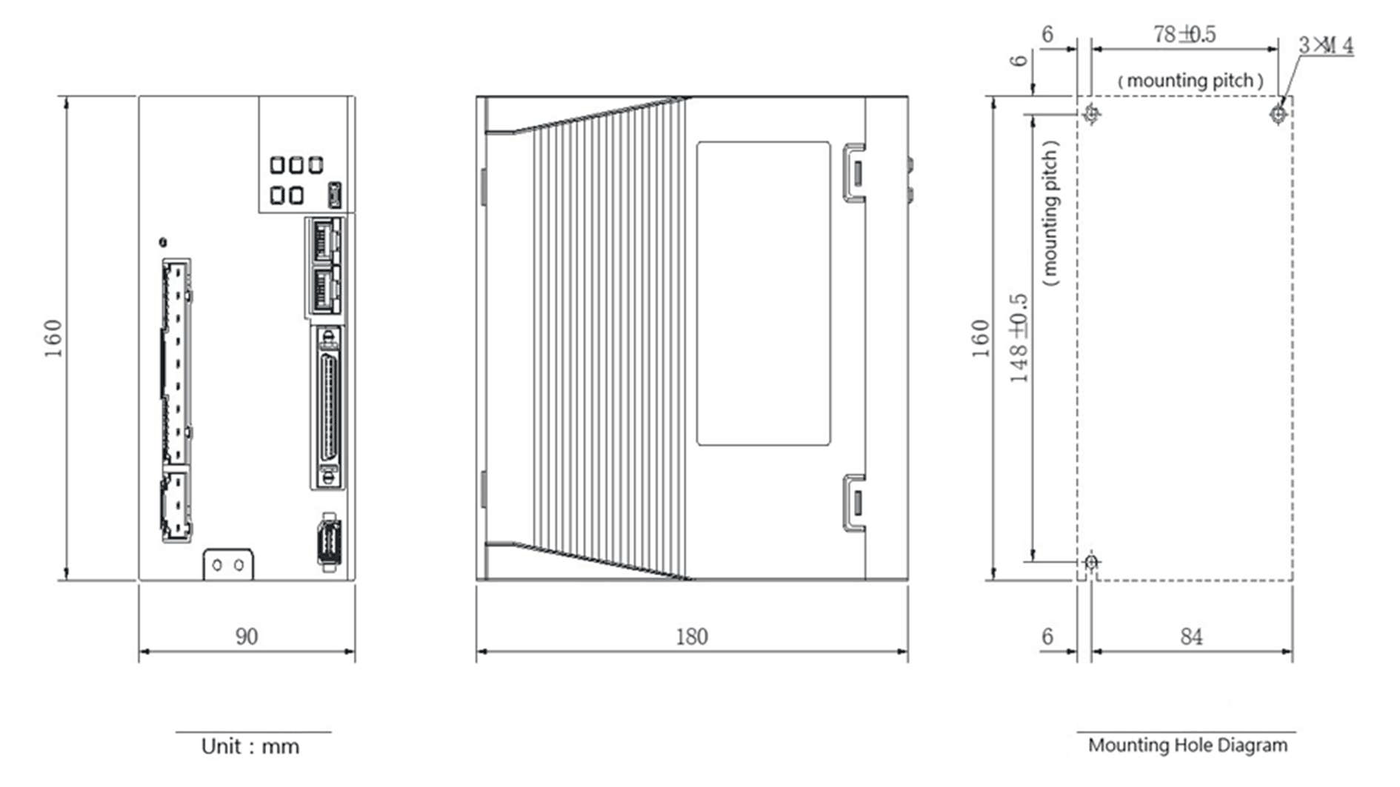
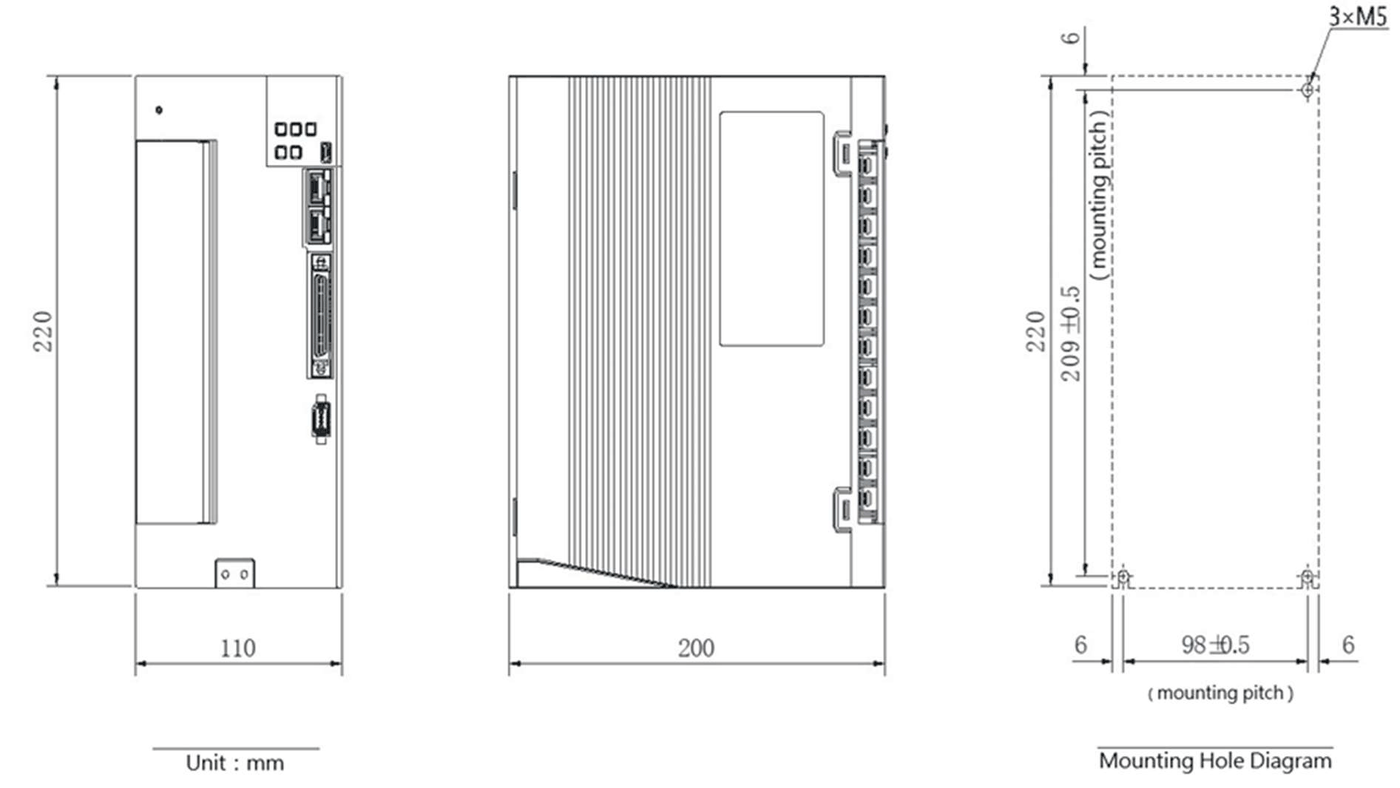
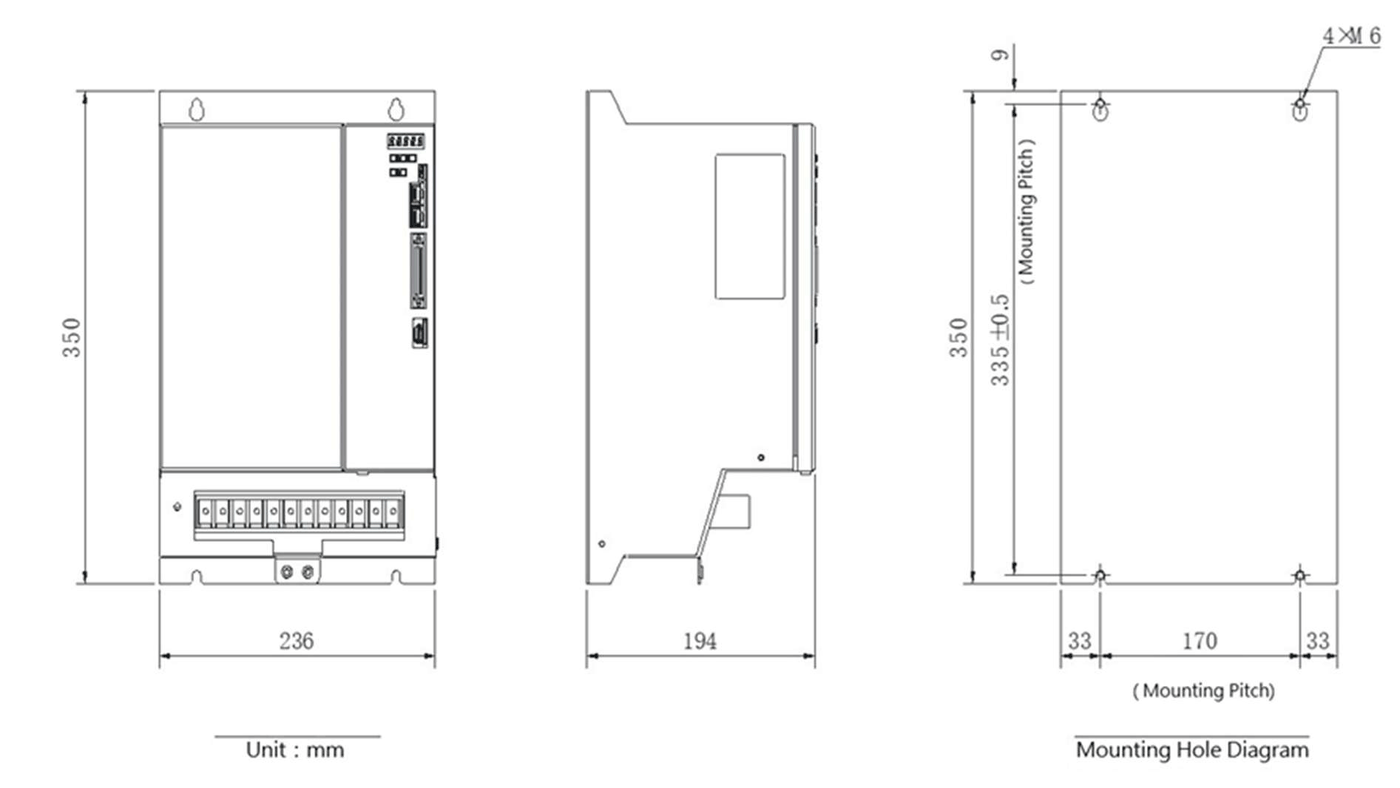
2.2 SC3 External Dimensions
◆ 220V: SC303AAD▯▯
◆ 220V: SC306AAF▯▯
380V: SC303ADE▯▯
◆ 220V: SC308AAG▯▯ / SC310AAH▯▯
380V: SC306ADH▯▯ / SC310ADI▯▯
◆ 380V: SC315ADK▯▯
◆ 380V: SC328ABL▯▯
Tip: press ← → to switch chapters, Ctrl+K to search