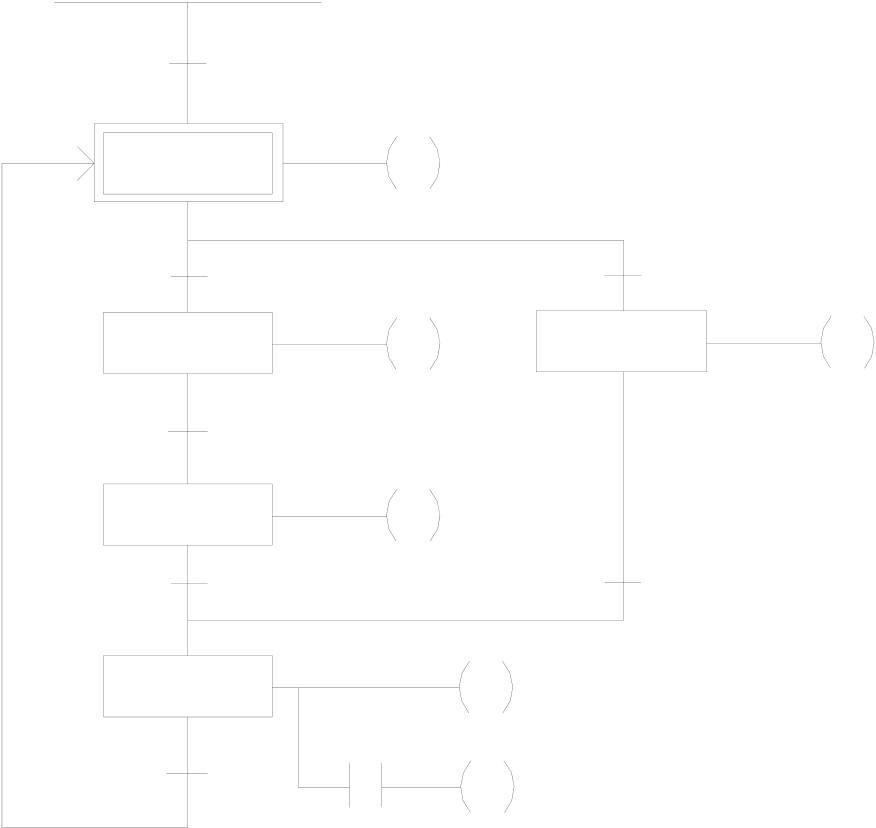


Structured programming design is a major trend in software design. The benefits are high readability, easy maintenance, convenient updating and high quality and reliability. For the control applications, consisted of many sequential tasks, designed by conventional ladder program design methodology usually makes others hard to maintain. Therefore, it is necessary to combine the current widely used ladder diagrams with the sequential controls made especially for machine working flow. With help from step instructions, the design work will become more efficient, time saving and controlled. This kind of design method that combines process control and ladder diagram together is called the step ladder language.
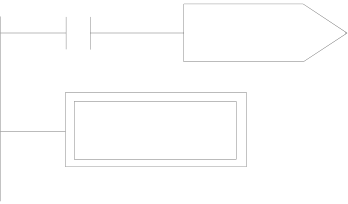
The basic unit of step ladder diagram is a step. A step is equivalent to a movement (step) in the machine operation where each movement has an output. The complete machine or the overall sequential control process is the combination of steps in serial or parallel. Its step-by-step sequential execution procedure allows others to be able to understand the machine operations thoroughly, so that design, operation, and maintenance will become more effective and simpler.
8.1The Operation Principle of Step Ladder Diagram
|
【Example】 |
Y0 |
【Description】 |
|
M1924 |
1. STP Sxxx is the symbol representing a step |
|
|
Sxxx that can be one of S0 ~S999. When |
||
|
STP S0 |
executing the step (status ON), the ladder diagram |
|
|
on the right will be executed and the previous step |
and output will become OFF.
|
X1 |
Y1 |
Y4 |
X2 |
Y2 |
2. M1924 is on for a scan time after program start. |
||
|
STP S20 |
Y3 |
STP S21 |
Hence, as soon as ON, the stop of the initial step |
||||
|
X3 |
S0 is entered (S0 ON) while the other steps are |
||||||
|
kept inactive, i.e. Y1~Y5 are all OFF. This means |
|||||||
|
STP S22 |
X5 |
M1924 ONÆS0 ONÆY0 ON and Y0 will remain |
|||||
|
X4 |
ON until one of the contacts X1 or X2 is ON. |
||||||
|
X10 |
3. Assume that X2 is ON first; the path to S21 will |
||||||
|
STP S23 |
|||||||
|
then be executed. |
|||||||
|
Y5 |
|||||||
|
X6 |
S21 ON S0 OFF |
|
Y2 ON |
||||
|
Y0 OFF |
|||||||

Y2 will remain ON until X5 is ON.
4. Assume that X5 is ON, the process will move
forward to step S23.
|
i.e. X5 ON⇒ |
|
S23 ON |
⇒ |
|
Y4 ON |
|
S21 OFF |
Y2 OFF |


Y4 and Y5 will remain ON until X6 is ON.
※If X10 is ON, then Y5 will be ON.
5. Assume that X6 is ON, the process will move
forward to S0.
|
S0 ON |
|
Y0 ON |
|
Y4、Y5 OFF |

Then, a control process cycle is completed and the
next control process cycle is entered.
8.2Basic Formation of Step Ladder Diagram
cSingle path
|
||||||||
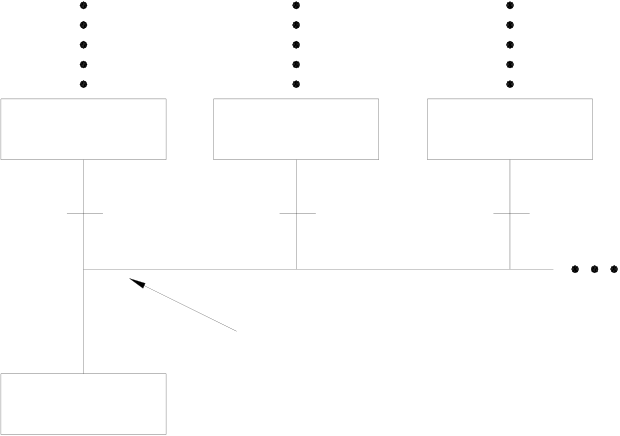
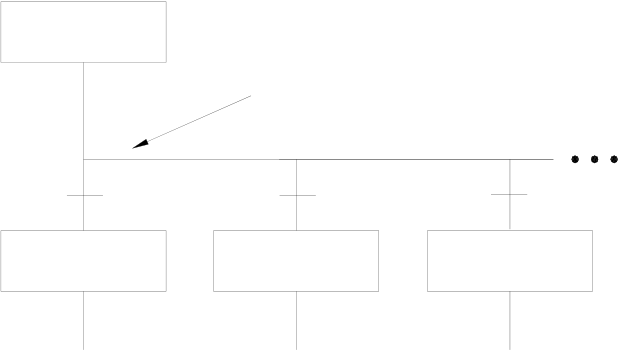
dSelective divergence/convergence
z Step S20 alone moves to step S21 through X0. z X0 can be changed to other serial or parallel combination of contacts.
|
STP S20 |
Selective divergence |
z Step S20 selects an only one path which divergent |
|
|
condition first met. E.g. X2 is ON first, then only the path |
|||
|
X0 |
X1 |
X2 |
of step S23 will be executed. |
|
z A divergence may have up to 8 paths maximum. |
|||
|
STP S21 |
STP S22 |
STP S23 |
z X1, X2, ….., X22 can all be replaced by the serial or |
parallel combination of other contacts.
|
STP S30 |
STP S31 |
STP S32 |
|
X20 |
X21 |
X22 |
Selective convergence
STP S40
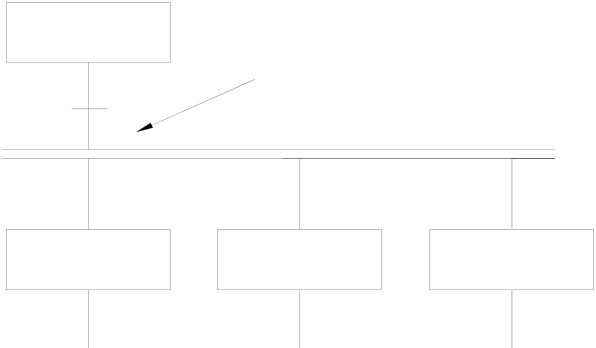
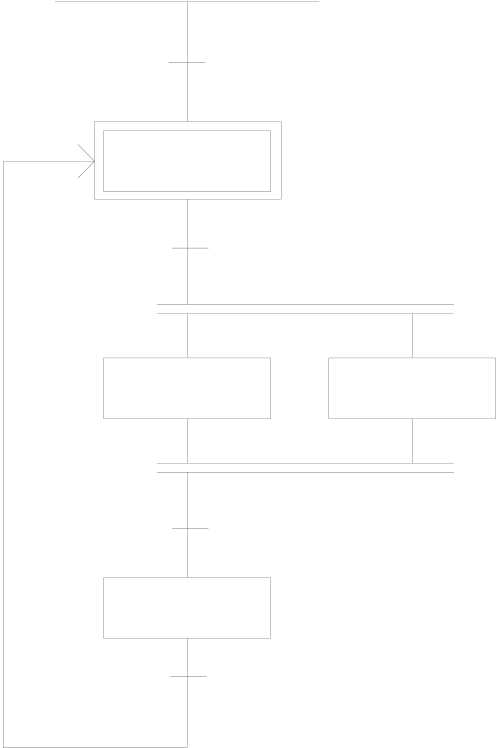
eSimultaneous divergence/convergence
|
STP S20 |
Simultaneous divergence |
z After X0 is ON, step S20 will simultaneously execute all |
|
X0 |
paths below it, i.e. all S21, S22, S23, and so on, are in |
|
|
action. |
z All divergent paths at a convergent point will be executed
|
STP S21 |
STP S22 |
STP S23 |
to the last step (e.g. S30, S31 and S32). When X1 is ON, |
they can then transfer to S40 for execution.
|
|
|
|
z The number of divergent paths must be the same as the |
|
|
|
|
|
|
|
|
|
|
|
STP S30 |
STP S31 |
STP S32 |
number of convergent paths. The maximum number of |
|
divergence/convergence path is 8. |
|||
|
X1 |
Simultaneous convergence |
||


STP S40
fJump
a. The same step loop
z There are 3 paths below step S20 as shown on the left.
|
STP S20 |
3-divergence |
Assume that X2 is ON, then the process can jump directly |
|
|
to step S23 to execute without going through the process |
|||
|
X0 |
X1 |
X2 |
of selective convergence. |
|
z The execution of simultaneous divergent paths can not be |
|||
|
STP S21 |
STP S22 |
S23 |
skipped. |
|
X3 |
X4 |
||
|
STP S23 |
2-convergence |
||
b. Different step loop
|
M1924 |
X4 |
X10 |
X12 |
|
STP S0 |
STP S7 |
||
|
X0 |
X11 |
||
|
STP S20 |
S30 |
STP S30 |
S21 |
|
X2 |
X1 |
||
|
STP S21 |
STP S31 |
||
|
X3 |
X3 |
gClosed Loop and Single Cycle
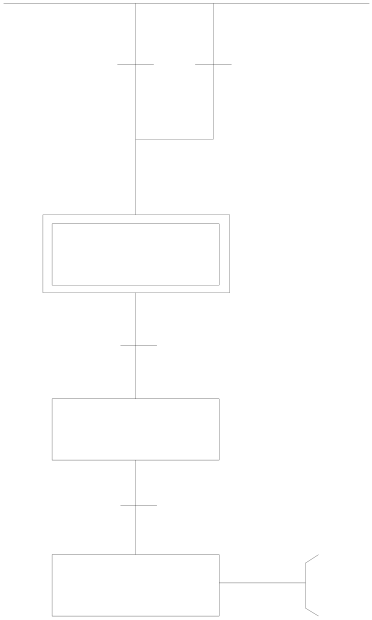
a. Closed Loop
|
M1924 |
z The initial step S1 is ON, endless cycle will be continued afterwards. S20 |
X0
STP S20 STP S21
X1
STP S22
X2
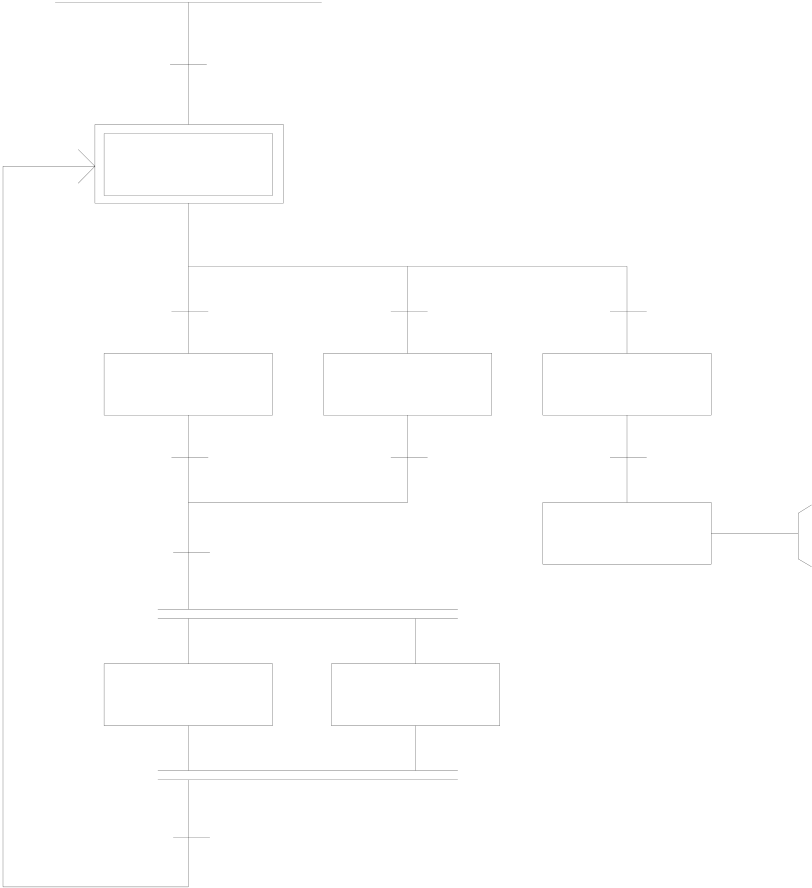
b. Single Cycle
|
M1924 |
X0 |
z When step S20 is ON, if X2 is also ON, then “RST S21” |
|
instruction will let S21 OFF which will stop the whole step |
process.
STP S0
X1
STP S20
X2
STP S21 RST S21
c. Mixed Process
M1924
STP S0
|
X0 |
X1 |
X2 |
RST S25 |
|
STP S20 |
STP S21 |
STP S24 |
|
|
X3 |
X4 |
X7 |
|
|
X5 |
STP S23 |
STP S25 |
|
|
STP S22 |
X6
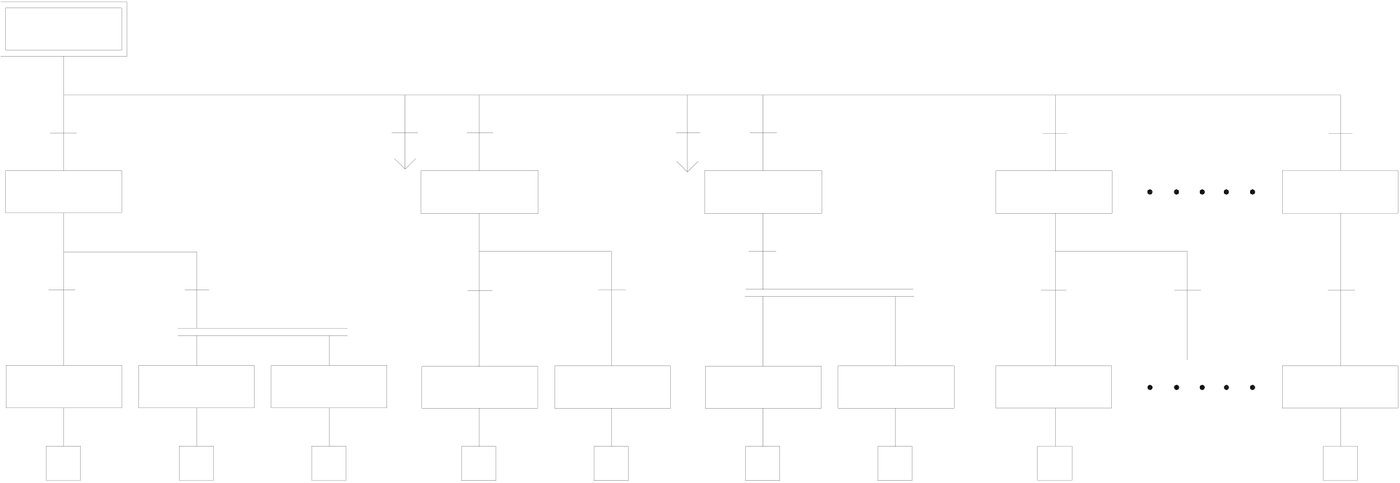
hCombined Application
A branch can have up to 8 branch loops
|
1 |
2 |
3 |
4 |
5 |
6 |
7 |
8 |
16 |
The maximum number of downward horizontal branch loops of an initial step is 16
8.3 Introduction of Step Instructions: STP, FROM, TO and STPEND
|
● |
STP Sx : S0≦Sx≦S7 (Displayed in WinProladder) |
or
STP Sx:S0≦Sx≦S7 (Displayed in FP-08)
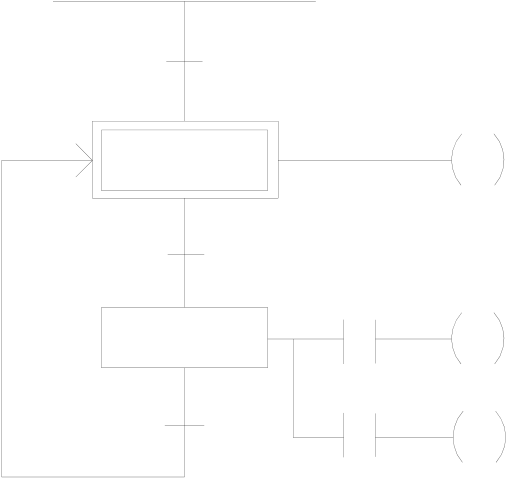
This instruction is the initial step instruction from where the step control of each machine process can be derived. Up to 8 initial steps can be used in the FBs series, i.e. a PLC can make up to 8 process controls simultaneously. Each step process can operate independently or generate results for the reference of other processes.
【Example 1】 Go to the initial step S0 after each start (ON)
|
WinProladder |
FP-08 |
M1924 |
|||||||||
|
M1924 |
TO S0 |
ORG |
||||||||||
|
STP S0 |
TO |
S0 |
||||||||||
|
STP |
S0 |
|||||||||||
【Example 2】 Each time the device is start to run or the manual button is pressed or the device is malfunction, then the device automatically enters the initial step S0 to standby.
|
WinProladder |
TO S0 |
FP-08 |
|||||||||||||||||||||||||||||
|
M1924 |
ORG |
M1924 |
||||||||||||||||||||||||||||||
|
OR |
X0 |
|||||||||||||||||||||||||||||||
|
X0 |
OR |
M0 |
||||||||||||||||||||||||||||||
|
TO |
S0 |
|||||||||||||||||||||||||||||||
|
M0 |
STP |
S0 |
||||||||||||||||||||||||||||||
|
Standby process program |
||||||||||||||||||||||||||||||||
Standby
|
STP S0 |
Process |
【Description】X0: Manual Button, M0: Abnormal Contact.
|
● |
STPSxxx : S20≦Sxxx≦S999(Displayed in WinProladder) |
or
STPSxxx : S20≦Sxxx≦S999(Displayed in FP-08)
This instruction is a step instruction, each step in a process represents a step of sequence. If the status of step is ON then the step is active and will execute the ladder program associate to the step.
【Example】
|
M1924 |
X1 |
Y0 |
WinProladder |
X10 |
TO S0 |
Y0 |
FP-08 |
M1924 |
|
M1924 |
ORG |
|||||||
|
TO |
S0 |
|||||||
|
STP S0 |
STP S0 |
TO S20 |
STP |
S0 |
||||
|
OUT |
Y0 |
|||||||
|
X10 |
Y1 |
FROM |
S0 |
|||||
|
AND |
X10 |
|||||||
|
STP S20 |
TO |
S20 |
||||||
|
X11 |
X2 |
Y2 |
STP S20 |
X1 |
TO S0 |
Y1 |
STP |
S20 |
|
OUT |
TR0 |
|||||||
|
X2 |
Y2 |
|||||||
|
AND |
X1 |
|||||||
|
OUT |
Y1 |
|||||||
|
X11 |
||||||||
|
LD |
TR0 |
|||||||
|
AND |
X2 |
|||||||
|
STPEND |
OUT |
Y2 |
||||||
|
FROM |
S20 |
|||||||
|
AND |
X11 |
|||||||
|
TO |
S0 |
STPEND
【Description】1. When ON, the initial step S0 is ON and Y0 is ON.
2. When transfer condition X10 is ON (in actual application, the transferring condition may be formed by the serial or parallel combination of the contacts X, Y, M, T and C), the step S20 is activated. The system will automatically turn S0 OFF in the current scan cycle and Y0 will be reset automatically to OFF.
|
i.e. X10 ON⇒ |
|
S20 ON |
⇒ |
X1 ON |
ÆY1 ON |
|
X2 ON |
ÆY2 ON |
||||
|
S0OFF |
|||||
|
Y0 OFF |
3. When the transfer condition X11 is ON, the step S0 is ON, Y0 is ON and S20, Y1 and Y2 will turn OFF at the same time.
|
i.e. X11 ON⇒ |
S0ON |
⇒ |
Y0 ON |
|
Y1 OFF |
|||
|
S20OFF |
|||
|
Y2 OFF |
|
● |
FROM Sxxx : S0≦Sxxx≦S999(Displayed in WinProladder) |
or
FROM Sxxx : S0≦Sxxx≦S999(Displayed in FP-08)
The instruction describes the source step of the transfer, i.e. moving from step Sxxx to the next step in coordination
with transfer condition.
【Example】
|
M1924 |
Y1 |
X0 |
Y0 |
Y2 |
X3 |
Y3 |
WinProladder |
X0 |
X7 |
TO S0 |
Y0 |
FP-08 |
M1924 |
|
M1924 |
ORG |
||||||||||||
|
TO |
S0 |
||||||||||||
|
STP S0 |
STP S0 |
TO S20 |
STP |
S0 |
|||||||||
|
AND |
X0 |
||||||||||||
|
X1 |
|||||||||||||
|
X2 |
OUT |
Y0 |
|||||||||||
|
X1 |
|||||||||||||
|
FROM |
S0 |
||||||||||||
|
STP S20 |
X2 |
TO S21 |
Y1 |
OUT TR |
0 |
||||||||
|
STP S20 |
STP S21 |
STP S22 |
|||||||||||
|
AND |
X1 |
||||||||||||
|
X5 |
X4 |
X6 |
X3 |
||||||||||
|
TO |
S20 |
||||||||||||
|
TO S22 |
|||||||||||||
|
LDTR |
0 |
||||||||||||
|
S0 |
|||||||||||||
|
X7 |
AND |
X2 |
|||||||||||
|
TO |
S21 |
||||||||||||
|
STP S23 |
Y4 |
STP S21 |
X4 |
TO S0 |
Y2 |
LDTR |
0 |
||||||
|
AND |
X3 |
||||||||||||
|
TO |
S22 |
||||||||||||
|
X8 |
|||||||||||||
|
STP |
S20 |
||||||||||||
|
STP S22 |
X5 |
TO S23 |
Y3 |
||||||||||
|
OUT |
Y1 |
||||||||||||
|
STP |
S21 |
||||||||||||
|
OUT |
Y2 |
||||||||||||
|
FROM S20 |
|||||||||||||
|
FROM |
S21 |
||||||||||||
|
FROM S22 |
X6 |
Y4 |
AND |
X4 |
|||||||||
|
TO |
S0 |
||||||||||||
|
STP |
S22 |
||||||||||||
|
STP S23 |
TO S0 |
||||||||||||
|
X8 |
|||||||||||||
|
OUT |
Y3 |
||||||||||||
|
FROM |
S20 |
||||||||||||
|
STPEND |
AND |
X5 |
|||||||||||
|
FROM |
S22 |
||||||||||||
|
AND |
X6 |
||||||||||||
ORLD
AND X7
TO S23
STP S23
OUT
Y4 FROM S23
AND X8
TO S0
STPEND
【Description】: 1. When ON, the initial step S0 is ON. If X0 is ON, then Y0 will be ON.
2. When S0 is ON: a. if X1 is ON, then step S20 will be ON and Y1 will be ON.
b. if X2 is ON, then step S21 will be ON and Y2 will be ON.
c. if X3 is ON, then step S22 will be ON and Y3 will be ON.
d. if X1, X2 and X3 are all ON simultaneous, then step S20 will have the priority to be ON first and either S21 or S22 will not be ON.
e. if X2 and X3 are ON at the same time, then step S21 will have the priority to be ON first and S22 will not be ON.
3. When S20 isON, if X5 and X7 are ON at the same time, then step S23 will be ON, Y4 will be ON and S20 and Y1 will be OFF.
4. When S21 is ON, if X4 is ON, then step S0 will be ON and S21 and Y2 will be OFF.
5. When S22 is ON, if X6 and X7 are ON at the same time, then step S23 will be ON, Y4 will be ON and S22 and Y3 will be OFF.
6. When S23 is ON, if X8 is ON, then step S0 will be ON and S23 and Y4 will be OFF.
|
● |
TO Sxxx : S0≦Sxxx≦S999(Displayed in WinProladder) |
or
TO Sxxx : S0≦Sxxx≦S999(Displayed in FP-08)
This instruction describes the step to be transferred to.
【Example】
|
M1924 |
Y1 |
X0 |
Y0 |
Y2 |
WinProladder |
X0 |
TO S0 |
Y0 |
FP-08 |
M1924 |
|
M1924 |
ORG |
|||||||||
|
TO |
S0 |
|||||||||
|
STP S0 |
STP |
S0 |
||||||||
|
STP S0 |
||||||||||
|
AND |
X0 |
|||||||||
|
STP S21 |
STP S20 |
X1 |
TO S20 |
Y1 |
OUT |
Y0 |
||||
|
X1 |
||||||||||
|
FROM |
S0 |
|||||||||
|
AND |
X1 |
|||||||||
|
STP S20 |
TO S21 |
|||||||||
|
TO |
S20 |
|||||||||
|
TO |
S21 |
|||||||||
|
Y3 |
||||||||||
|
X2 |
STP |
S20 |
||||||||
|
OUT |
Y1 |
|||||||||
|
Y2 |
||||||||||
|
STP S22 |
STP |
S21 |
||||||||
|
STP S21 |
||||||||||
|
OUT |
Y2 |
|||||||||
|
X3 |
X4 |
Y4 |
STP S22 |
X2 |
TO S22 |
Y3 |
FROM |
S21 |
||
|
AND |
X2 |
|||||||||
|
TO |
S22 |
|||||||||
|
STP |
S22 |
|||||||||
|
STP S23 |
X3 |
TO S23 |
Y4 |
OUT |
Y3 |
|||||
|
FROM S20 |
||||||||||
|
FROM |
S20 |
|||||||||
|
X5 |
||||||||||
|
FROM |
S22 |
|||||||||
|
FROM S22 |
||||||||||
|
X4 |
AND |
X3 |
||||||||
|
TO |
S23 |
|||||||||
|
STP S23 |
||||||||||
|
STP |
S23 |
|||||||||
|
STPEND |
X5 |
TO S0 |
AND |
X4 |
||||||
|
OUT |
Y4 |
|||||||||
|
FROM |
S23 |
|||||||||
|
AND |
X5 |
|||||||||
|
TO |
S0 |
|||||||||
STPEND
【Description】: 1. When ON, the initial step S0 is ON. If X0 is ON, then Y0 will be ON.
2. When S0 is ON: if X1 is ON, then steps S20 and S21 will be ON simultaneously and Y1 and Y2 will also be ON.
3. When S21 is ON: if X2 is ON, then step S22 will be ON, Y3 will be ON and S21 and Y2 will be OFF.
4. When S20 and S22 are ON at the same time and the transferring condition X3 is ON, then step S23 will be ON (if X4 is ON, then Y4 will be ON) and S20 and S22 will automatically turn OFF and Y1 and Y3 will also turn OFF.
5. When S23 is ON: if X5 is ON, then the process will transfer back to the initial step, i.e. So will be ON and S23 and Y4 will be OFF.
|
● |
STPEND :(Displayed in WinProladder) |
or
STPEND:(Displayed in FP-08)
This instruction represents the end of a process. It is necessary to include this instruction so all processes can be operated correctly.
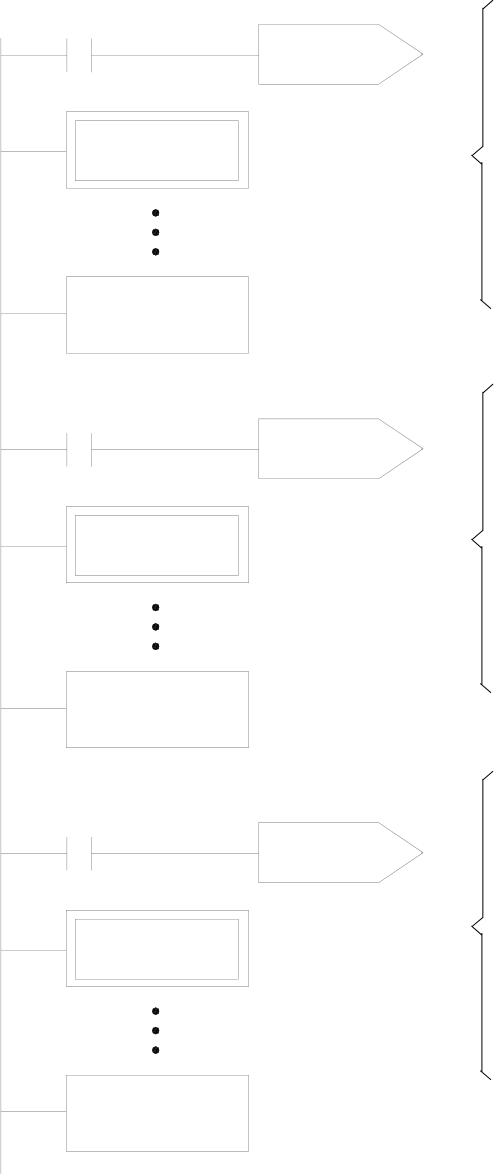
A PLC can have up to 8 step processes (S0~S7) and is able to control them simultaneously. Therefore, up to 8 STPEND instructions can be obtained.
【Example】
|
M1924 |
WinProladder |
TO S0 |
FP-08 |
M1924 |
|
M1924 |
ORG |
|||
|
TO |
S0 |
|||
|
STP S0 |
STP S0 |
TO S1 |
STP |
S0 |
|
․ |
||||
|
|
․ |
|||
|
STPEND |
․ |
|||
|
M1924 |
||||
|
STPEND |
||||
|
STPEND |
||||
|
ORG |
||||
|
M1924 |
||||
|
TO |
S1 |
|||
|
M1924 |
STP S1 |
TO S7 |
STP |
S1 |
|
․ |
||||
|
STP S1 |
||||
|
․ |
||||
|
|
․ |
|||
|
STPEND |
||||
|
|
M1924 |
|||
|
STPEND |
||||
|
STPEND |
||||
|
ORG |
||||
|
M1924 |
||||
|
TO |
S7 |
|||
|
M1924 |
STP S7 |
STP |
S7 |
|
|
․ |
||||
|
STP S7 |
․ |
|||
|
|
STPEND |
․ |
||
|
STPEND |
||||
|
|
||||
|
STPEND |


【Description】 When ON, the 8 step processes will be active simultaneously.
8.4Notes for Writing a Step Ladder Diagram
【Notes】
● In actual applications, the ladder diagram can be used together with the step ladder.
● There are 8 steps, S0~S7, that can be used as the starting point and are called the “initial steps”.
● When PLC starts operating, it is necessary to activate the initial step. The M1924 (the first scan ON signal) provided
by the system may be used to activate the initial step.
● Except the initial step, the start of any other steps must be driven by other step.
● It is necessary to have an initial step and the final STPEND instruction in a step ladder diagram to complete a step
process program.
● There are 980 steps, S20~S999, available that can be used freely. However, used numbers cannot be repeated.
S500~S999 are retentive(The range can be modified by users), can be used if it is required to continue the machine
process after power is off.
● Basically a step must consists of three parts which are control output, transition conditions and transition targets.
● MC and SKP instructions cannot be used in a step program and the sub-programs. It’s recommended that JMP
instruction should be avoided as much as possible.
● If the output point is required to stay ON after the step is divergent to other step, it is necessary to use the SET
instruction to control the output point and use RST instruction to clear the output point to OFF.
● Looking down from an initial step, the maximum number of horizontal paths is 16. However, a step is only allowed to
have up to 8 branch paths.
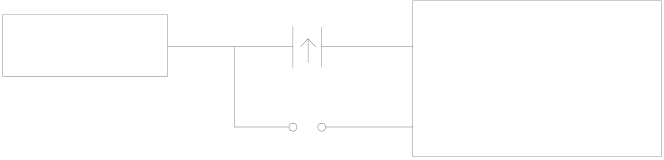
● When M1918=0(default), if a PULSE type function instruction is used in master control loop (FUN 0) or a step
program, it is necessary to connect a TU instruction before the function instruction. For example,
S20
|
STP S20 |
C0 |
5 |
|
PV : |
When M1918=1, the TU instruction is not required, e.g.:
|
STP S20 |
C0 |
5 |
|
PV : |
Example 1
|
M1924 |
X0 |
Y0 |
X4 |
Y2 |
WinProladder |
X0 |
X2 |
TO S0 |
Y0 |
FP-08 |
ORG |
M1924 |
|
|
M1924 |
|||||||||||||
|
Net0 |
TO |
S0 |
|||||||||||
|
STP S0 |
|||||||||||||
|
STP S0 |
STP |
S0 |
|||||||||||
|
TO S20 |
AND |
X0 |
|||||||||||
|
X1 |
X1 |
||||||||||||
|
Y1 |
X3 |
OUT |
Y0 |
||||||||||
|
S0 |
|||||||||||||
|
X2 |
FROM |
S0 |
|||||||||||
|
X3 |
|||||||||||||
|
AND |
X1 |
||||||||||||
|
TO S0 |
|||||||||||||
|
STP S20 |
STP S21 |
||||||||||||
|
OUT TR |
0 |
||||||||||||
|
X5 |
X11 |
X6 |
STP S20 |
X5 |
X4 |
TO S21 |
Y1 |
Net1 |
AND |
X2 |
|||
|
TO |
S20 |
||||||||||||
|
X7 |
Y3 |
LD TR |
0 |
||||||||||
|
AND |
X3 |
||||||||||||
|
STP S22 |
TO |
S0 |
|||||||||||
|
X7 |
Y2 |
||||||||||||
|
LD TR |
0 |
||||||||||||
|
STP S21 |
|||||||||||||
|
X8 |
AND |
X4 |
|||||||||||
|
TO |
S21 |
||||||||||||
|
FROM S20 |
X6 |
TO S22 |
Y3 |
Net2 |
STP |
S20 |
|||||||
|
OUT |
Y1 |
||||||||||||
|
FROM S21 |
|||||||||||||
|
Net3 |
STP |
S21 |
|||||||||||
|
X11 |
|||||||||||||
|
STP S22 |
|||||||||||||
|
OUT |
Y2 |
||||||||||||
|
STPEND |
X8 |
TO S0 |
Net4 |
FROM |
S20 |
||||||||
|
AND |
X5 |
||||||||||||
|
FROM |
S21 |
||||||||||||
|
AND |
X6 |
||||||||||||
ORLD
|
AND |
X7 |
|||
|
TO |
S22 |
|||
|
Net5 |
STP |
S22 |
||
|
AND |
X11 |
|||
|
OUT |
Y3 |
|||
|
FROM |
S22 |
|||
|
AND |
X8 |
|||
|
TO |
S0 |
|||
|
Description 1. Input the condition to initial step S0 |
Net6 |
STPEND |
2. Input the S0 and the divergent conditions of S20, S0 and S21 3. Input the S20
4. Input the S21
5. Input the convergence of S20 and S21
6. Input the S22
Example 2
|
M1924 |
WinProladder |
TO S0 |
FP-08 |
|
ORG |
M1924 |
||||||
|
M1924 |
||||||||||||
|
Net0 |
TO |
S0 |
||||||||||
|
STP S0 |
X0 |
Y0 |
Y3 |
STP S0 |
X0 |
X2 |
TO S20 |
Y0 |
Net1 |
STP |
S0 |
|
|
AND |
X0 |
|||||||||||
|
X1 |
||||||||||||
|
X1 |
||||||||||||
|
OUT |
Y0 |
|||||||||||
|
FROM |
S0 |
|||||||||||
|
X2 |
Y1 |
X3 |
STP S20 |
X4 |
X3 |
TO S22 |
Y1 |
|||||
|
AND |
X1 |
|||||||||||
|
STP S20 |
STP S22 |
OUT TR |
0 |
|||||||||
|
AND |
X2 |
|||||||||||
|
Y2 |
||||||||||||
|
X4 |
X6 |
|||||||||||
|
TO |
S20 |
|||||||||||
|
LD TR |
0 |
|||||||||||
|
STP S21 |
||||||||||||
|
TO S21 |
Y2 |
AND |
X3 |
|||||||||
|
X5 |
||||||||||||
|
TO |
S22 |
|||||||||||
|
X11 |
Y4 |
STP S21 |
X5 |
X7 |
Net2 |
STP |
S20 |
|||||
|
X7 |
STP S22 |
Y3 |
OUT |
Y1 |
||||||||
|
FROM |
S20 |
|||||||||||
|
STP S23 |
AND |
X4 |
||||||||||
|
TO |
S21 |
|||||||||||
|
X8 |
FROM S21 |
X6 |
TO S23 |
Net3 |
STP |
S21 |
||||||
|
FROM S22 |
OUT |
Y2 |
||||||||||
|
STP S23 |
X11 |
Y4 |
Net4 |
STP |
S22 |
|||||||
|
OUT |
Y3 |
|||||||||||
|
STPEND |
X8 |
TO S0 |
Net5 |
FROM |
S21 |
|||||||
|
AND |
X5 |
|||||||||||
|
FROM |
S22 |
|||||||||||
|
AND |
X6 |

ORLD
|
AND |
X7 |
|||
|
TO |
S23 |
|||
|
Net6 |
STP |
S23 |
||
|
AND |
X11 |
|||
|
OUT |
Y4 |
|||
|
FROM |
S23 |
|||
|
AND |
X8 |
|||
|
TO |
S0 |
|||
|
Description 1. Input the condition to initial step S0 |
Net7 |
STPEND |
2. Input the S0 and the divergent condition of S20 and S22
3. Input the S20
4. Input the S21
5. Input the S22
6. Input the convergence of S21 and S22
7. Input the S23
Example 3
|
M1924 |
Y0 |
STP S22 |
X4 |
Y5 |
WinProladder |
X1 |
X7 |
TO S0 |
Y0 |
FP-08 |
ORG |
M1924 |
|
M1924 |
||||||||||||
|
Net0 |
||||||||||||
|
TO |
S0 |
|||||||||||
|
STP S0 |
Y1 |
STP S0 |
TO S20 |
Net1 |
STP |
S0 |
||||||
|
OUT |
Y0 |
|||||||||||
|
X1 |
FROM |
S0 |
||||||||||
|
X4 |
Y1 |
OUT TR |
0 |
|||||||||
|
TO S24 |
||||||||||||
|
AND |
X1 |
|||||||||||
|
STP S20 |
STP S24 |
|||||||||||
|
TO |
S20 |
|||||||||||
|
X2 |
Y2 |
X6 |
STP S20 |
X2 |
TO S21 |
Net2 |
LD TR |
0 |
||||
|
AND |
X4 |
|||||||||||
|
Y3 |
||||||||||||
|
STP S21 |
TO |
S24 |
||||||||||
|
Y2 |
STP |
S20 |
||||||||||
|
TO S22 |
||||||||||||
|
X3 |
OUT |
Y1 |
||||||||||
|
FROM |
S20 |
|||||||||||
|
STP S23 |
Y4 |
STP S21 |
X3 |
TO S23 |
Y3 |
AND |
X2 |
|||||
|
TO |
S21 |
|||||||||||
|
STP S22 |
||||||||||||
|
X5 |
TO |
S22 |
||||||||||
|
Net3 |
||||||||||||
|
STP |
S21 |
|||||||||||
|
FROM S21 |
||||||||||||
|
X7 |
||||||||||||
|
OUT |
Y2 |
|||||||||||
|
FROM S22 |
X5 |
TO S0 |
Y4 |
Net4 |
STP |
S22 |
||||||
|
OUT |
Y3 |
|||||||||||
|
STP S23 |
||||||||||||
|
Y5 |
FROM |
S21 |
||||||||||
|
Net5 |
||||||||||||
|
STP S24 |
||||||||||||
|
FROM |
S22 |
|||||||||||
|
AND |
X3 |
|||||||||||
|
FROM S23 |
X6 |
Net6 |
TO |
S23 |
||||||||
|
FROM S24 |
STP |
S23 |
||||||||||
|
OUT |
Y4 |
|||||||||||
|
STPEND |
Net7 |
STP |
S24 |
|||||||||
|
OUT |
Y5 |
|||||||||||
|
Net8 |
FROM |
S23 |
||||||||||
|
AND |
X5 |
|||||||||||
|
FROM |
S24 |
|||||||||||
|
AND |
X6 |
ORLD
|
AND |
X7 |
|||
|
TO |
S0 |
|||
|
Description 1. Input the condition to initial step S0 |
Net9 |
STPEND |
2. Input the S0 and the divergences of S20 and S24
3. Input the S20
4. Input the S20 and the divergences of S21 and S22
5. Input the S21
6. Input the S22
7. Input the convergences of S21 and S22
8. Input the S23
9. Input the S24
10. Input the convergences of S23 and S24
8.5 Application Examples
|
Example 1 Grasp an object from tank A and put it in Tank B |
X4 : Right Limit |
||
|
X0 : Start |
X1 : Left Limit |
||
|
LS |
|||
Y0 : Move Left
Motor Leadscrew Y1 : Move Right
Y2 : Lift Up X2 : Upper Limit
Y3 : Stretch Down X3 : Lower Limit
Arm
Claw (Y4)
Tank A Tank B
M1924
|
STP S0 |
Start |
Return to the origin (claw released |
1S delay to ensure the object is firmly grasped |
|
at the left limit and the upper limit) |
|||
|
X0 |
|||
|
Lower Limit |
Arm stretches downward |
||
|
STP S20 |
|||
|
X3 |
|||
|
Stop stretching downward |
|||
|
STP S21 |
|||
|
Claw grasps (after 1S) |
before being lifted up |
||
|
T0 |
1S Delaly |
Arm lifts up |
1S delay to ensure the object has been |
|
STP S22 |
|||
|
Upper Limit |
|||
|
X2 |
|||
|
Stop lifting up |
|||
|
STP S23 |
|||
|
Right Limit |
|||
|
Move arm to the right |
|||
|
X4 |
|||
|
Stop moving to the right |
|||
|
STP S24 |
|||
|
Lower Limit |
Arm stretches downwards |
||
|
X3 |
|||
|
Stop stretching downwards |
|||
|
STP S25 |
|||
|
1S Delay |
Release claw (after 1S) |
completely released before lifting the arm up |
|
|
T1 |
|||
|
Upper Limit |
Arm lifts up |
||
|
STP S26 |
|||
|
X2 |
|||
|
Left Limit |
Stop lift up |
||
|
STP S27 |
|||
|
Move arm to the left |
|||
|
X1 |
|
WinProladder |
X1 |
TO S0 |
Release claw |
FP-08 |
M1924 |
|
M1924 |
ORG |
||||
|
TO |
S0 |
||||
|
STP S0 |
STP |
S0 |
|||
|
Y4 |
|||||
|
OUT TR |
0 |
||||
|
Y0 |
OUT NOT |
Y4 |
|||
|
AND NOT |
X1 |
||||
|
Return to the left limit |
|||||
|
OUT |
Y0 |
||||
|
STP S20 |
X2 |
Y2 |
Return to the upper limit |
||
|
LD TR |
0 |
||||
|
AND NOT |
X2 |
||||
|
X0 |
OUT |
Y2 |
|||
|
TO S20 |
Turn the switch ON before moving to S20 |
||||
|
FROM |
S0 |
||||
|
AND |
X0 |
||||
|
Y3 |
Stretch arm downward |
||||
|
TO |
S20 |
||||
|
STP |
S20 |
||||
|
STP S21 |
X3 |
TO S21 |
Move to S21 after stretching to the lower |
OUT |
Y3 |
|
limit |
FROM |
S20 |
|||
|
Claw grasps (since the SET instruction is |
AND |
X3 |
|||
|
EN |
|||||
|
SET Y4 |
TO |
S21 |
|||
|
used, Y4 should remain ON after departing |
|||||
|
STP |
S21 |
||||
|
from STP S21) |
|||||
|
SET |
Y4 |
||||
|
STP S22 |
EN |
T0 100 |
Divergent into S22 after 1S |
T0 PV: |
100 |
|
T0 |
FROM |
S21 |
|||
|
TO S22 |
|||||
|
AND |
T0 |
||||
|
Lift the arm up |
|||||
|
TO |
S22 |
||||
|
Y2 |
|||||
|
STP |
S22 |
||||
|
Divergent into S23 after reaching the upper |
|||||
|
OUT |
Y2 |
||||
|
STP S23 |
X2 |
TO S23 |
limit |
FROM |
S22 |
|
AND |
X2 |
||||
|
Move arm to the right |
|||||
|
TO |
S23 |
||||
|
Y1 |
|||||
|
Divergent into S24 after moving to the right |
STP |
S23 |
|||
|
X4 |
TO S24 |
OUT |
Y1 |
||
|
limit |
|||||
|
FROM |
S23 |
||||
|
Stretch the arm downward |
AND |
X4 |
|||
|
TO |
S24 |
||||
|
STP S24 |
X3 |
Y3 |
Divergent into S25 after stretching to the |
||
|
STP |
S24 |
||||
|
lower limit |
OUT |
Y3 |
|||
|
TO S25 |
FROM |
S24 |
|||
|
Release claw |
|||||
|
AND |
X3 |
||||
|
STP S25 |
EN |
Delay for 1S |
TO |
S25 |
|
|
RST Y4 |
|||||
|
STP |
S25 |
||||
|
RST |
Y4 |
||||
|
STP S26 |
EN |
T1 100 |
Transfer into S26 after 1S |
T1 PV: |
100 |
|
FROM |
S25 |
||||
|
T1 |
Lift the arm up |
||||
|
TO S26 |
AND |
T1 |
|||
|
TO |
S26 |
||||
|
Y2 |
Divergent into S27 after reaching the upper |
||||
|
STP |
S26 |
||||
|
limit |
OUT |
Y2 |
|||
|
STP S27 |
X2 |
TO S27 |
FROM |
S26 |
|
|
Move the arm to the left |
|||||
|
AND |
X2 |
||||
|
Divergent into S0 after moving to the left |
TO |
S27 |
|||
|
Y0 |
|||||
|
STP |
S27 |
||||
|
limit (a complete cycle) |
|||||
|
OUT |
Y0 |
||||
|
STPEND |
X1 |
TO S0 |
FROM |
S27 |
|
|
AND |
X1 |
||||
|
TO |
S0 |
||||
|
STPEND |
|
Example 2 Liquid Stirring Process |
Liquid |
No Liquid Limit |
||
|
Dried |
Empty Limit |
|||
|
Switch |
||||
|
X2 |
||||
|
Value Y7 |
||||
|
Value 1 Y5 |
||||
CH0 : R3840
|
Weighing |
Value 1 Y6 |
Clear Water Clean Water |
Value Y9
Stirring Unit
Value 4 Y10
Finished Product
Outlet
|
|
Y8 |
Stirring |
X4 |
|
Electromagnetic Switch |
Motor |
Overload Switch |
|
|
Input Points: Empty limit switch X1 |
No liquid limit switch X2
Empty limit switch X3
Over-load switch X4
Warning clear button X5
Start button X6
Water washing button X7
Warning Indicators: Empty dried material Y1
Insufficient liquid Y2
Empty stirring unit Y3
Motor over-load Y4
Output Points: Dried material inlet valve Y5
Dried material inlet valve Y6
Liquid inlet valve Y7
Motor start electromagnetic valve Y8
Clean water inlet valve Y9
Finished product outlet valve Y10
Weighing Output: CH0(R3840)
M1918=0
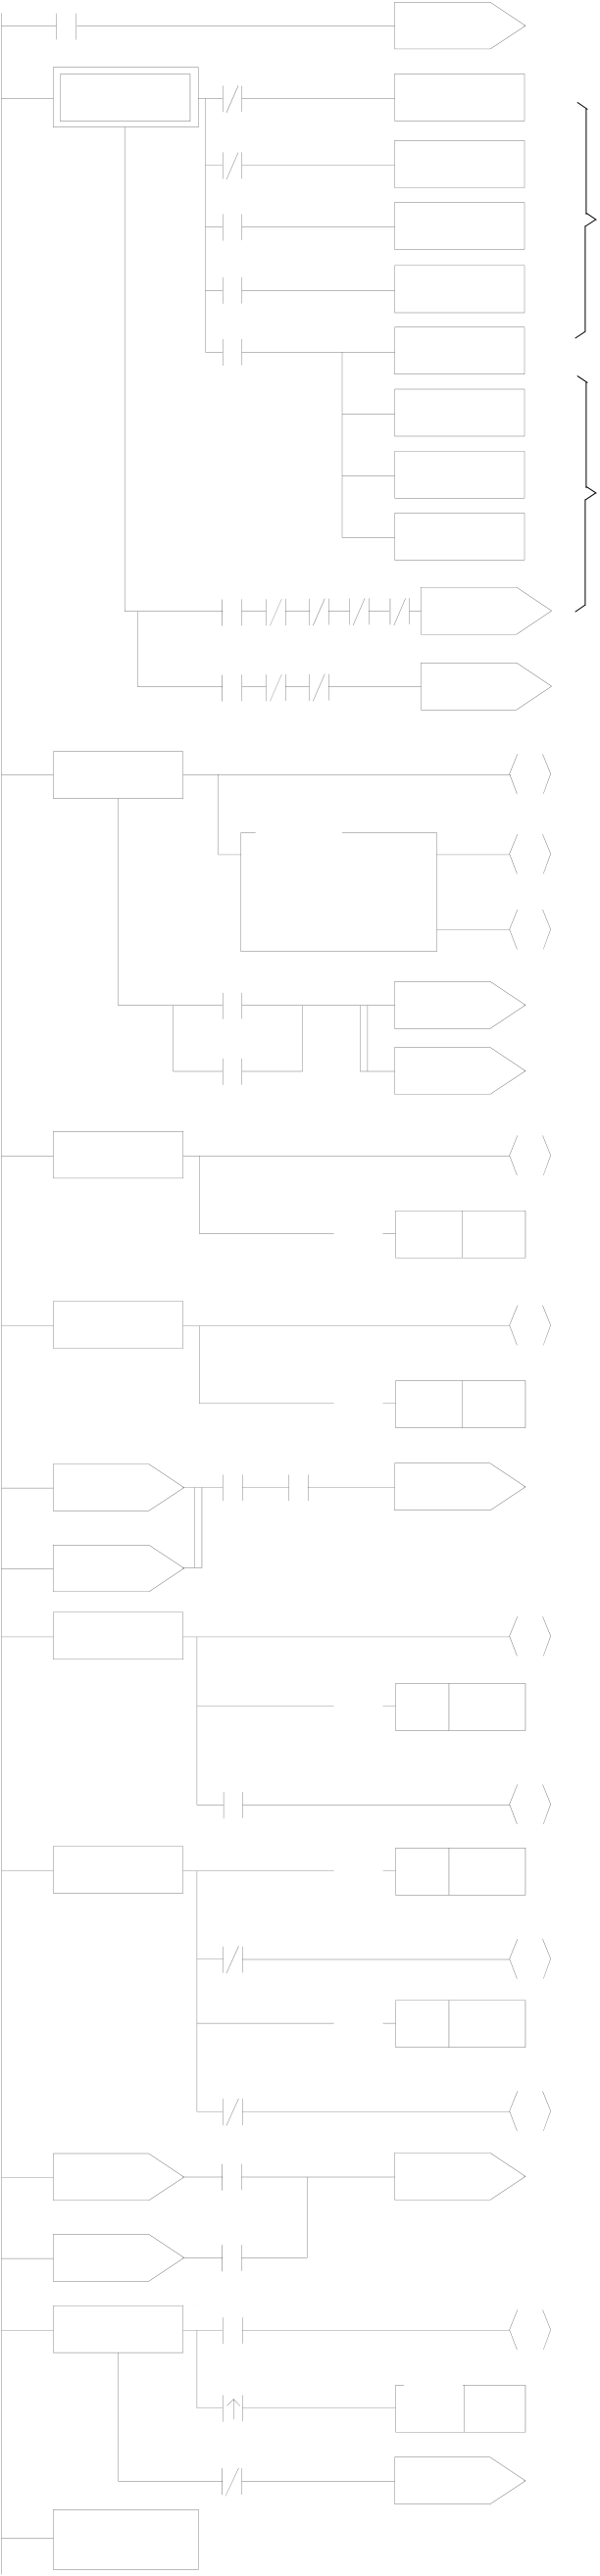
|
WinProladder |
Warning indicators |
FP-08 |
M1924 |
STP |
S22 |
||||||||
|
M1924 |
TO S0 |
ORG |
|||||||||||
|
TO |
S0 |
OUT |
Y7 |
||||||||||
|
STP S0 |
X1 |
SET Y1 |
|||||||||||
|
STP |
S0 |
T1 PV: 800 |
|||||||||||
|
X2 |
SET Y2 |
OUT TR |
0 |
FROM |
S21 |
||||||||
|
X3 |
SET Y3 |
AND NOT |
X1 |
FROM |
S22 |
||||||||
|
SET |
Y1 |
AND |
T0 |
||||||||||
|
X4 |
SET Y4 |
||||||||||||
|
LD TR |
0 |
AND |
T1 |
||||||||||
|
X5 |
RST Y1 |
||||||||||||
|
AND NOT |
X2 |
TO |
S23 |
||||||||||
|
RST Y2 |
Reset warning |
SET |
Y2 |
STP |
S23 |
||||||||
|
LD TR |
0 |
OUT TR |
0 |
||||||||||
|
RST Y3 |
|||||||||||||
|
AND |
X3 |
OUT |
Y8 |
||||||||||
|
RST Y4 |
Production start |
||||||||||||
|
SET |
Y3 |
LD TR |
0 |
||||||||||
|
X6 |
Y1 |
Y2 |
Y3 |
Y4 |
TO S20 |
||||||||
|
LD TR |
0 |
T2 PV: |
4500 |
||||||||||
|
X7 |
Y3 |
Y4 |
TO S24 |
AND |
X4 |
LD TR |
0 |
||||||
|
Water washing start |
SET |
Y4 |
AND |
X4 |
|||||||||
|
Y5 |
LD TR |
0 |
OUT |
Y4 |
|||||||||
|
STP S20 |
|||||||||||||
|
17CMP |
M0 |
Input weighing |
AND |
X5 |
STP |
S24 |
|||||||
|
RST |
Y1 |
OUT TR |
0 |
||||||||||
|
Sa : R3840 |
M1 |
||||||||||||
|
RST |
Y2 |
T3 PV: |
500 |
||||||||||
|
Status after weighing |
RST |
Y3 |
LD TR |
0 |
|||||||||
|
M0 |
TO S21 |
||||||||||||
|
RST |
Y4 |
AND NOT |
T3 |
||||||||||
|
M1 |
TO S22 |
FROM |
S0 |
OUT |
Y9 |
||||||||
|
Divergent into S21 and S22 |
|||||||||||||
|
Y6 |
OUT TR |
1 |
LD TR |
0 |
|||||||||
|
STP S21 |
Input material to stirring |
AND |
X6 |
T4 PV: |
1500 |
||||||||
|
ENT0 500 |
unit |
AND NOT |
Y1 |
LD TR |
0 |
||||||||
|
AND NOT |
Y2 |
AND NOT |
T4 |
||||||||||
|
Y7 |
Add liquid to stirring unit |
||||||||||||
|
AND NOT |
Y3 |
OUT |
Y10 |
||||||||||
|
STP S22 |
|||||||||||||
|
AND NOT |
Y4 |
FROM |
S23 |
||||||||||
|
ENT1 800 |
|||||||||||||
|
TO |
S20 |
AND |
T2 |
||||||||||
|
FROM S21 |
T0 |
T1 |
TO S23 |
LD TR |
1 |
FROM |
S24 |
||||||
|
Complete dried material |
AND |
X7 |
AND |
T4 |
|||||||||
|
FROM S22 |
and liquid input, transfer |
AND NOT |
Y3 |
ORLD |
S25 |
||||||||
|
Y8 |
the status to S23 |
AND NOT |
Y4 |
TO |
|||||||||
|
STP S23 |
|||||||||||||
|
TO |
S24 |
STP |
S25 |
||||||||||
|
ENT2 4500 |
Stirring timer |
STP |
S20 |
OUT TR |
0 |
||||||||
|
X4 |
Y4 |
Wash stirring unit |
OUT |
Y5 |
AND |
X3 |
|||||||
|
FUN |
17 |
OUT |
Y10 |
||||||||||
|
STP S24 |
ENT3 500 |
||||||||||||
|
Sa:R3840 |
LD TR |
0 |
|||||||||||
|
T3 |
Y9 |
Sb:R0 |
0 |
AND TU |
S25 |
||||||||
|
Input clean water |
|||||||||||||
|
FO |
FUN |
15DP |
|||||||||||
|
ENT4 1500 |
Drain water out |
OUT |
M0 |
D:R10 |
S25 |
||||||||
|
FO |
1 |
FROM |
|||||||||||
|
T4 |
Y10 |
||||||||||||
|
OUT |
M1 |
AND NOT |
X3 |
||||||||||
|
FROM S23 |
T2 |
TO S25 |
Output finished product |
FROM |
S20 |
TO |
S0 |
||||||
|
LD |
M0 |
STPEND |
|||||||||||
|
T4 |
|||||||||||||
|
FROM S24 |
OR |
M1 |
|||||||||||
|
STP S25 |
X3 |
Y10 |
|||||||||||
|
ANDLD |
|||||||||||||
|
and accumulate the cycle |
TO |
S21 |
|||||||||||
|
S25 |
15DP |
||||||||||||
|
TO |
S22 |
||||||||||||
|
X3 |
TO S0 |
||||||||||||
|
STP |
S21 |
||||||||||||
|
STPEND |
OUT |
Y6 |
|||||||||||
|
T0 PV: |
500 |
||||||||||||
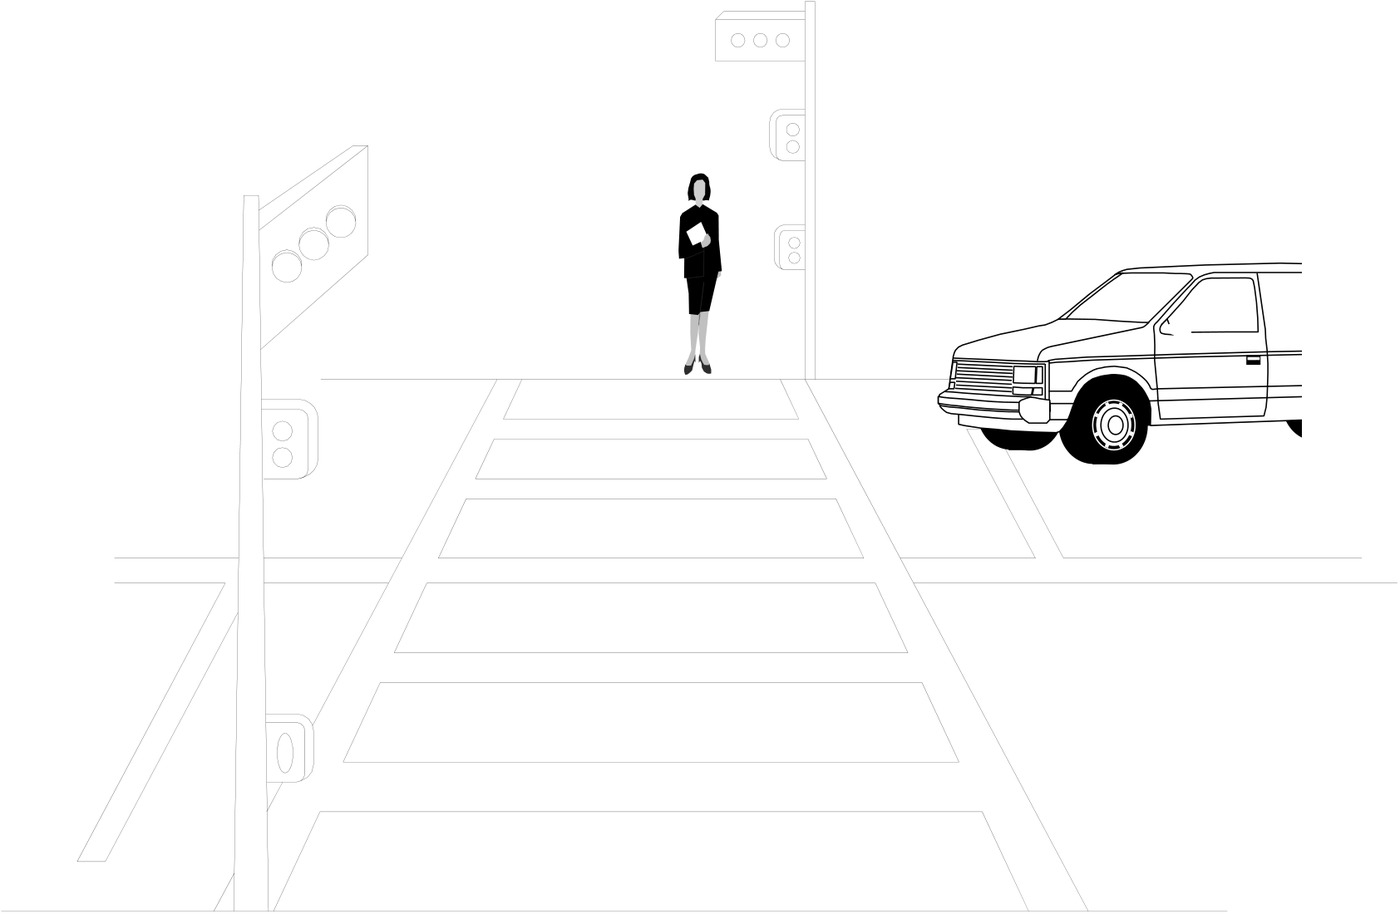
|
Example 3 Pedestrian Crossing Lights Y0 (Red) Y0 (Red) Y1 (Amber) Y1 (Amber) Y2 (Green) Y2 (Green) Y4 Y4 (Green) (Green) X0 X0 |
Y3 (Red) Y3 (Red) Y4 (Green) Y4 (Green) X1 X1 |
|
|
Input Points: |
Pedestrian Push Button X0 |
|
Output Points: |
Road Red Light Y0 |
Pedestrian Push Button X1
M1918=0
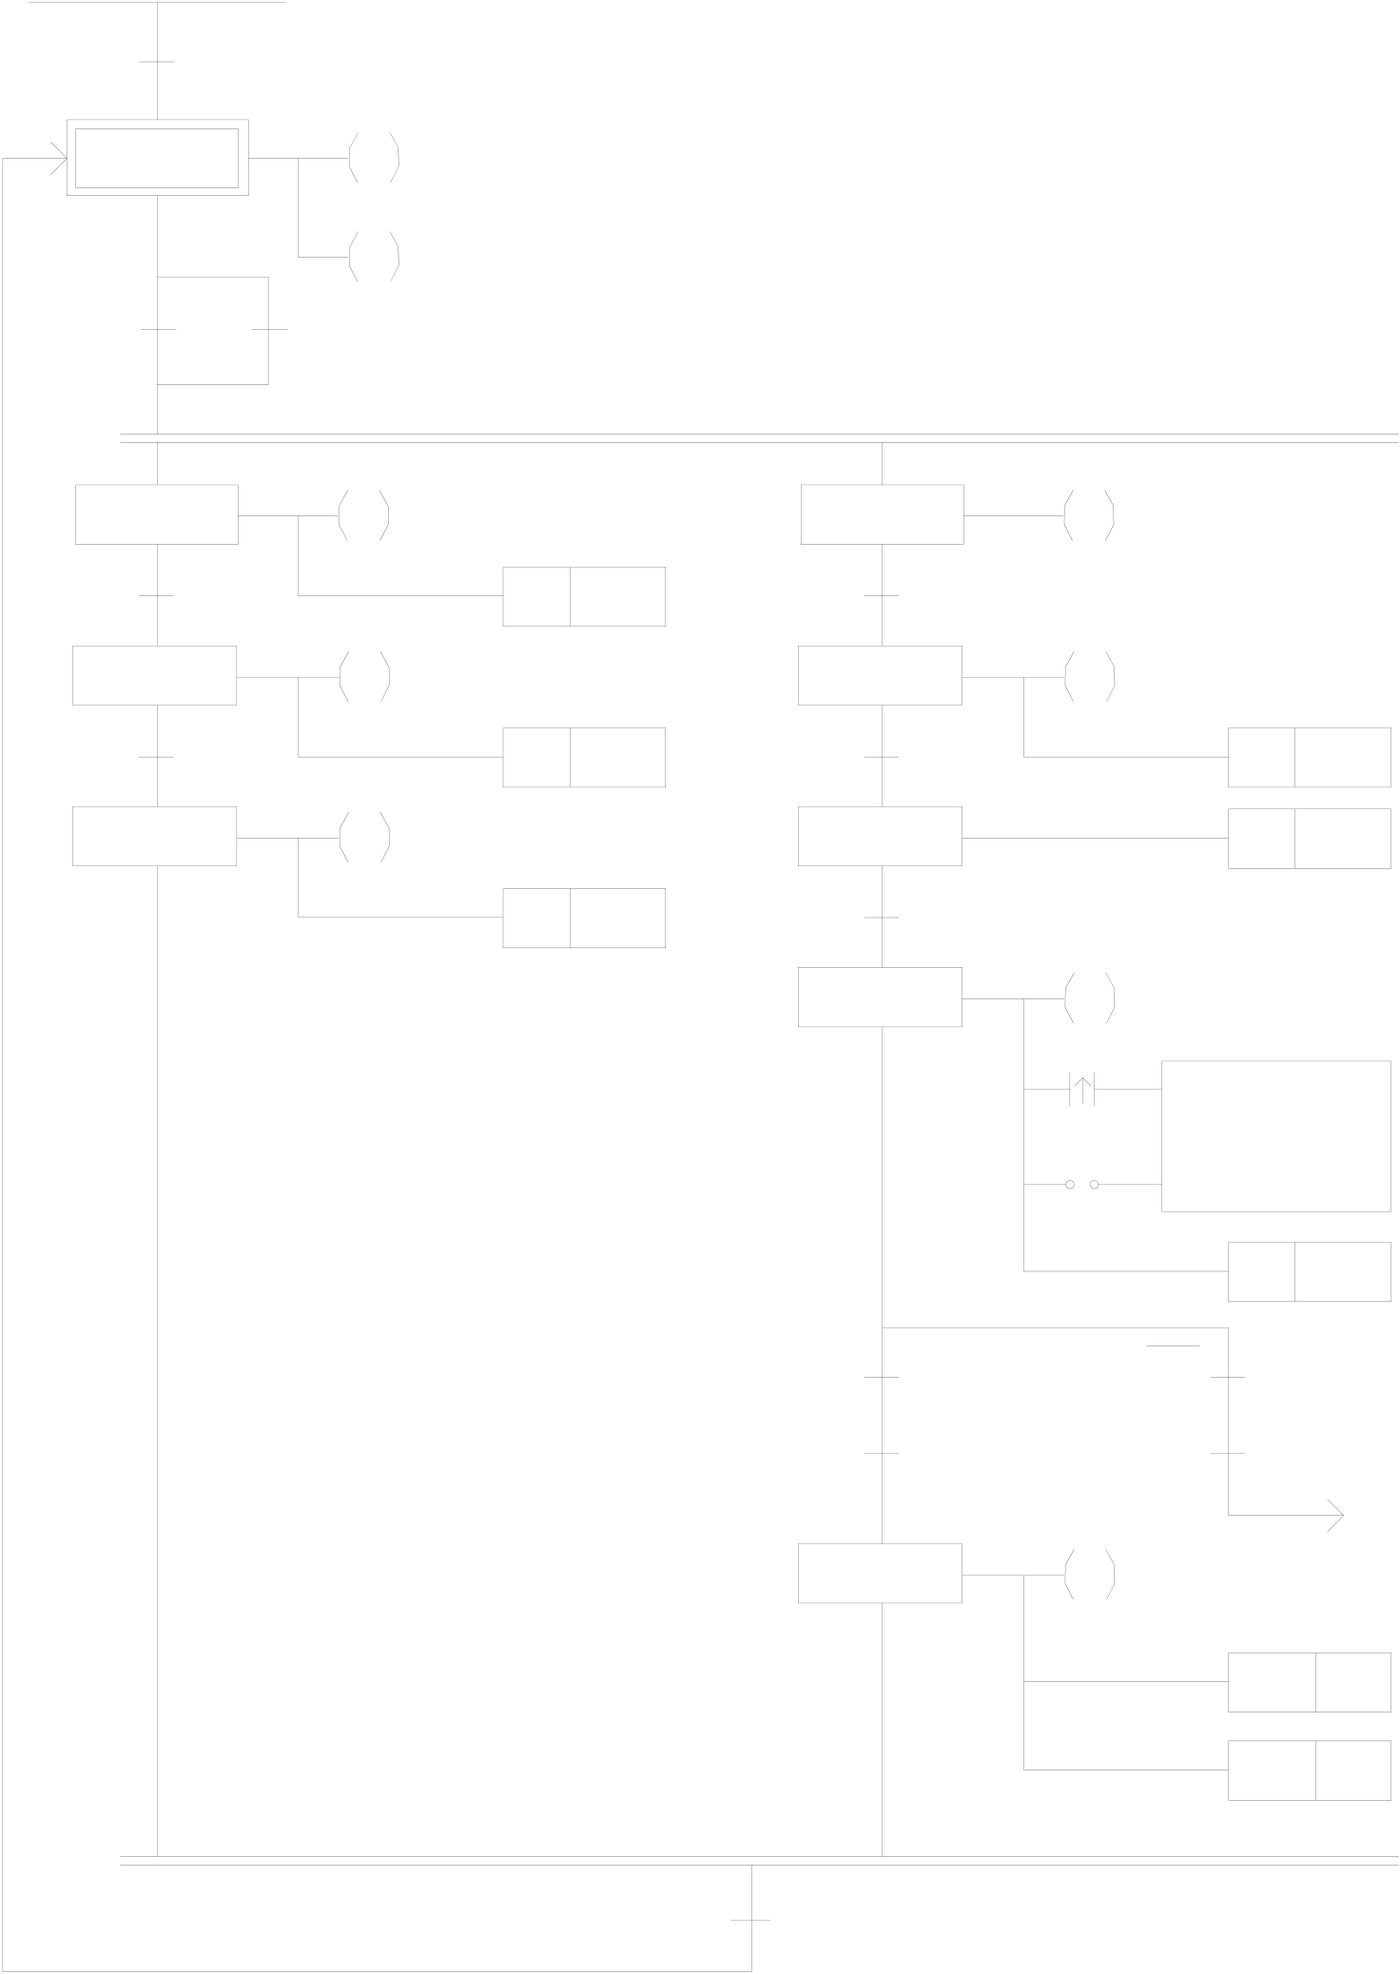
● Pedestrian Crossing Lights Control Process Diagram
M1924
Y2
STP S0 Road Green Light
Y3
Pedestrian Crossing Light
|
X0 |
X1 |
Pedestrian Push Button |
STP S30 |
Y3 |
Pedestrian Crossing |
|
|
Y2 |
||||||
|
STP S20 |
||||||
|
Road Green Light |
||||||
|
Red Light |
||||||
|
T0 |
Y1 |
T0 3000 |
T2 |
Y4 |
Pedestrian Crossing |
|
|
STP S21 |
STP S31 |
|||||
|
Road Amber Light |
||||||
|
Green Light |
||||||
|
T1 |
T3 |
Y4 |
T3 2000 |
|||
|
Y0 |
T1 500 |
|||||
|
STP S22 |
STP S32 |
T4 100 |
||||
|
Road Red Light |
||||||
|
T4 |
||||||
|
T2 500 |
||||||
|
STP S33 |
Pedestrian Crossing |
|||||
|
Green Light BLink |
||||||
S33
C1
PV : 6
T5 100
|
C1 |
Y3 |
C1 |
|
T5 |
T5 |
|
|
STP S34 |
S32 |
|
|
Pedestrian Crossing |
||
|
Red Light |
RST C1
T6 100
T6
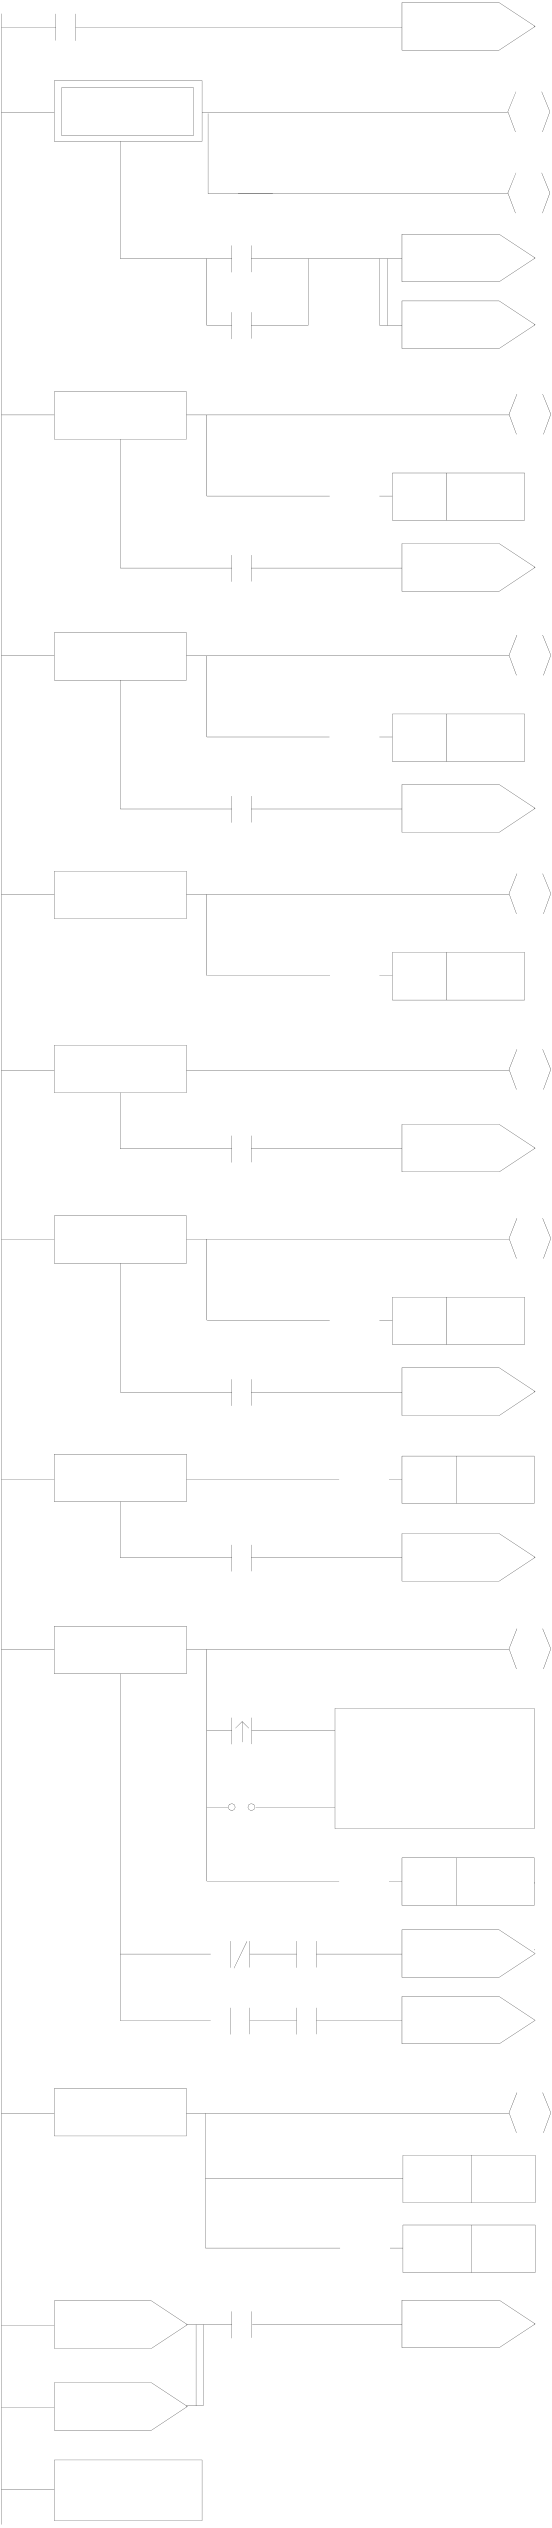
|
● |
Pedestrian Crossing Lights Control Program |
FP-08 |
M1924 |
STP |
S32 |
||
|
WinProladder |
|||||||
|
M1924 |
TO S0 |
ORG |
|||||
|
TO |
S0 |
T4 PV: |
100 |
||||
|
Y2 |
|||||||
|
STP S0 |
STP |
S0 |
FROM |
S32 |
|||
|
Y3 |
OUT |
Y2 |
AND |
T4 |
|||
|
X0 |
TO S20 |
OUT |
Y3 |
TO |
S33 |
||
|
X1 |
TO S30 |
FROM |
S0 |
STP |
S33 |
||
|
Y2 |
LD |
X0 |
OUT TR |
0 |
|||
|
STP S20 |
OR |
X1 |
OUT |
Y4 |
|||
|
ENT0 3000 |
ANDLD |
S20 |
LD TR |
0 |
|||
|
TO |
AND TU |
S33 |
|||||
|
T0 |
TO S21 |
||||||
|
TO |
S30 |
LD |
OPEN |
||||
|
Y1 |
STP |
S20 |
C1 PV: |
6 |
|||
|
STP S21 |
|||||||
|
ENT1 500 |
OUT |
Y2 |
LD TR |
0 |
|||
|
T0 PV: |
3000 |
T5 PV: |
100 |
||||
|
T1 |
TO S22 |
||||||
|
FROM |
S20 |
FROM |
S33 |
||||
|
Y0 |
AND |
T0 |
OUT TR |
1 |
|||
|
STP S22 |
|||||||
|
TO |
S21 |
AND NOT |
C1 |
||||
|
ENT2 500 |
STP |
S21 |
AND |
T5 |
|||
|
Y3 |
|||||||
|
OUT |
Y1 |
TO |
S32 |
||||
|
STP S30 |
|||||||
|
T1 PV: |
500 |
LD TR |
1 |
||||
|
T2 |
TO S31 |
||||||
|
FROM |
S21 |
AND |
C1 |
||||
|
Y4 |
AND |
T1 |
AND |
T5 |
|||
|
STP S31 |
|||||||
|
TO |
S22 |
TO |
S34 |
||||
|
ENT3 2000 |
STP |
S22 |
STP |
S34 |
|||
|
T3 |
TO S32 |
||||||
|
OUT |
Y0 |
OUT |
Y3 |
||||
|
T2 PV: |
500 |
RST |
C1 |
||||
|
STP S32 |
ENT4 100 |
||||||
|
STP |
S30 |
T6 PV: |
100 |
||||
|
T4 |
TO S33 |
||||||
|
OUT |
Y3 |
FROM |
S22 |
||||
|
Y4 |
FROM |
S30 |
FROM |
S34 |
|||
|
STP S33 |
AND |
T2 |
AND |
T6 |
|||
|
S33 |
|||||||
|
TO |
S31 |
TO |
S0 |
||||
|
C1 |
|||||||
|
STP |
S31 |
STPEND |
|||||
|
PV : 6 |
|||||||
|
ENT5 100 |
OUT |
Y4 |
|||||
|
T3 PV: |
2000 |
||||||
|
C1 |
T5 |
TO S32 |
|||||
|
FROM |
S31 |
||||||
|
C1 |
T5 |
TO S34 |
|||||
|
AND |
T3 |
||||||
|
Y3 |
|||||||
|
TO |
S32 |
||||||
|
STP S34 |
|||||||
RST C1
ENT6 100
|
FROM S22 |
T6 |
TO S0 |
FROM S34
STPEND
8.6Syntax Check Error Codes for Step Instruction
The error codes for the usage of step instruction are as follows:
E51 : TO(S0-S7) must begin with ORG instruction.
E52 : TO(S20-S999) can’t begin with ORG instruction.
E53 : TO instruction without matched FROM instruction.
E54 : To instruction must comes after TO, AND, OR, ANDLD or ORLD instruction.
E56 : The instructions before FROM must be AND, OR, ANDLD or ORLD E57 :The instruction after FROM can’t be a coil or a function
E58 :Coil or function must before FROM while in STEP network
E59 : More than 8 TO# at same network.
E60 : More than 8 FROM# at same network.
E61 : TO(S0-S19) must locate at first row of the network.
E62 : A contact occupies the location for TO instruction.
E72 : Duplicated TO Sxx instruction.
E73 : Duplicated STP sxx instruction.
E74 : Duplicated FROM sxx instruction.
E76 : STP(S0~S19) without a matched STPEND or STPEND without a matched STP(S0~S19). E78 : TO(S20~S999), STP (S20~S999) or FROM instructions comes before or without STP(S0~S19). E79 : STP Sxx or FROM Sxx instructions comes before or without TO Sxx.
E80 : FROM Sxx instruction comes before or without STP Sxx.
E81 : The max. level of branches must <=16.
E82 : The max. no. of branches with same level must <=16.
E83 : Not place the step instruction with TO->STP->FROM sequence.
E84 : The definition of STP# sequence not follow the TO# sequence.
E85 : Convergence do not match the corresponding divergence.
E86 : Illegal usage of STP or FROM before convergent with TO instruction.
E87 : STP# or FROM# comes before corresponding TO#.
E88 : During this branch, STP# or FROM# comes before the corresponding TO#.
E89 : FROM# comes before corresponding TO# or STP#.
E90 : Invalid To# usage in the simultaneous branch.
E91 : Flow control function cannot be used in the step ladder region
Tip: press ← → to switch chapters, Ctrl+K to search