EtherCAT Function and Configuration
This section describes the EtherCAT related function and configuration. EtherCAT is an industrial Ethernet technology developed by Beckhoff Automation in Germany. The connection type is a network system with one master station and multiple slave stations. It is also a configuration tool based on EtherCAT Slave Information (ESI). Currently, the PDO is designed in fixed type and it is not opened for the user to set manually. Indicated below is the setting page:
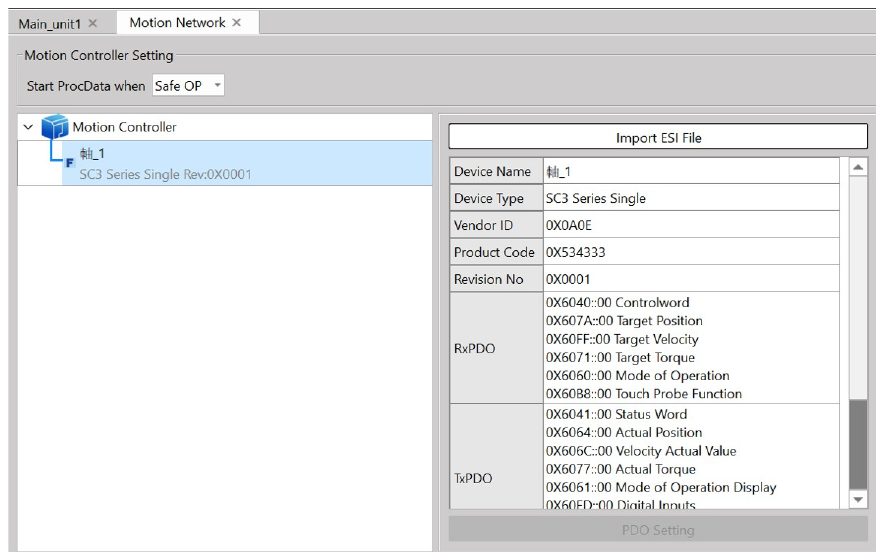
Listed below is the PDO setting:
|
PDO Type |
Index |
Name |
|
RxPDO |
0x6040 |
Control word |
|
0x607A |
Target position |
|
|
0x60FF |
Target velocity |
|
|
0x6071 |
Target Torque |
|
|
0x6060 |
Mode Of Operation |
|
|
0x60B8 |
Touch Probe Function |
|
|
TxPDO |
0x6041 |
Status Word |
|
0x6064 |
Actual Position |
|
|
0x606C |
Velocity actual value |
|
|
0x6077 |
Actual Torque |
|
|
0x6061 |
Mode Of Operation Display |
|
|
0x60FD |
Digital inputs |
|
|
0x603F |
Error code |
|
|
0x60BA |
Touch Probe Pos1 Pos Value |
Provided below are the parameters and the unit required for the cyclic synchronous position, speed and torque control modes.
Target under Cyclic Synchronous Position Control (CSP) Mode:
|
Index |
Name |
Unit |
Type |
Access |
PDO Mapping |
|
603Fh |
Error Code |
– |
U16 |
RO |
TxPDO |
|
6040h |
Control Word |
– |
U16 |
RW |
RxPDO |
|
6041h |
Status Word |
– |
U16 |
RO |
TxPDO |
|
6062h |
Position Demand Value |
pulse |
I32 |
RO |
TxPDO |
|
6064h |
Position Actual Value |
pulse |
I32 |
RO |
TxPDO |
|
6065h |
Following Error Window |
pulse |
U32 |
RW |
No |
|
6072h |
Max Torque |
0.1% |
U16 |
RW |
RxPDO |
|
6077h |
Torque Actual Value |
0.1% |
I16 |
RO |
TxPDO |
|
607Ah |
Target Position |
pulse |
I32 |
RW |
RxPDO |
|
6080h |
Max Motor Speed |
r/min |
U32 |
RW |
RxPDO |
|
60B0h |
Position Offset |
pulse |
I32 |
RW |
RxPDO |
|
60B1h |
Velocity Offset |
Command unit/s |
I32 |
RW |
RxPDO |
|
60B2h |
Torque Offset |
0.1% |
I16 |
RW |
RxPDO |
|
60F4h |
Following Error Actual value |
pulse |
I32 |
RO |
TxPDO |
|
60FDh |
Digital Inputs |
– |
U32 |
RO |
TxPDO |
Target under Cyclic Synchronous Speed Control (CSV) Mode:
|
Index |
Name |
Unit |
Type |
Access |
PDO Mapping |
|
603Fh |
Error Code |
– |
U16 |
RO |
TxPDO |
|
6040h |
Control Word |
– |
U16 |
RW |
RxPDO |
|
6041h |
Status Word |
– |
U16 |
RO |
TxPDO |
|
6072h |
Max Torque |
0.1% |
U16 |
RW |
RxPDO |
|
6080h |
Max Motor Speed |
r/min |
U32 |
RW |
RxPDO |
|
60B1h |
Velocity Offset |
Command unit/s |
I32 |
RW |
RxPDO |
|
60B2h |
Torque Offset |
0.1% |
I16 |
RW |
RxPDO |
|
60FFh |
Target Velocity |
Command unit/s |
I32 |
RW |
RxPDO |
Target under Cyclic Synchronous Torque Control (CST) Mode:
|
Index |
Name |
Unit |
Type |
Access |
PDO Mapping |
|
603Fh |
Error Code |
– |
U16 |
RO |
TxPDO |
|
6040h |
Control Word |
– |
U16 |
RW |
RxPDO |
|
6041h |
Status Word |
– |
U16 |
RO |
TxPDO |
|
6071h |
Target Torque |
0.1% |
U16 |
RW |
RxPDO |
|
6072h |
Max Torque |
0.1% |
U16 |
RW |
RxPDO |
|
6080h |
Max Motor Speed |
r/min |
U32 |
RW |
RxPDO |
|
60B2h |
Torque Offset |
0.1% |
I16 |
RW |
RxPDO |
Tip: press ← → to switch chapters, Ctrl+K to search