HOME Return
When using Relative Encoder as the displacement detector, normally the user needs to execute the return action for use as the reference of creating the positioning coordinate and such action is called mechanical HOME return (searching for mechanical zero point).
Indicated below is the mechanical HOME reset mode for NC Servo:
10-1 Mode 100: Forward-Falling Trigger
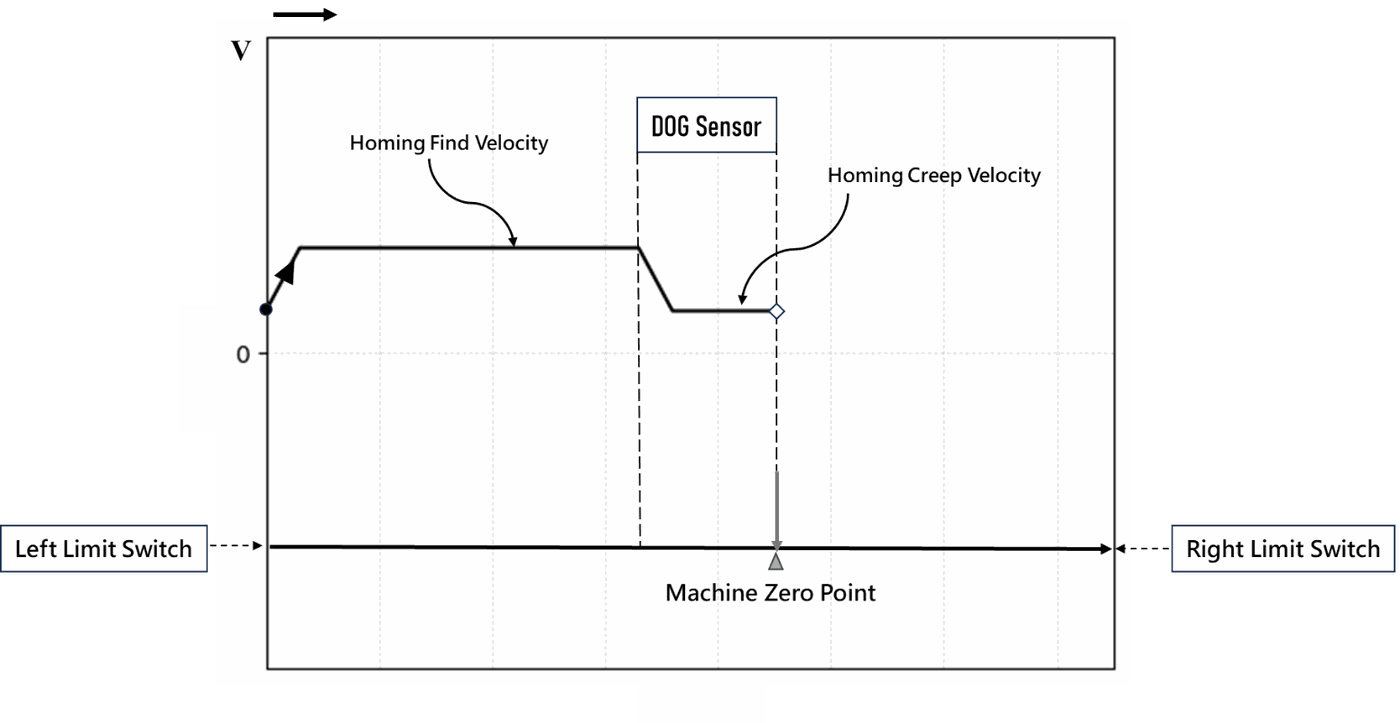
Action Description
The zero starting point is located to the left of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
c. The moment the signal is sensed away from Zero, this point is the Machine Zero Position.
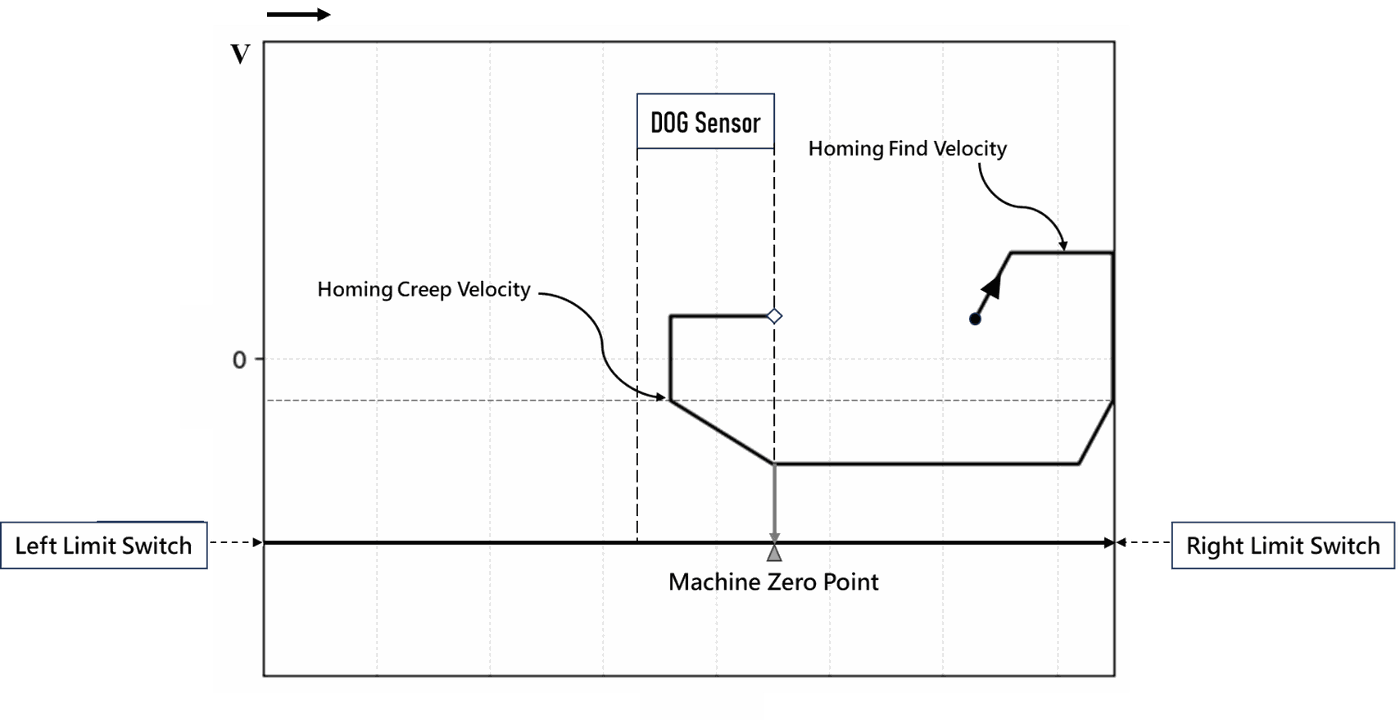
Action Description
The zero starting point is located to the right of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
d. The moment the signal is sensed away from Zero, this point is the Machine Zero Position.
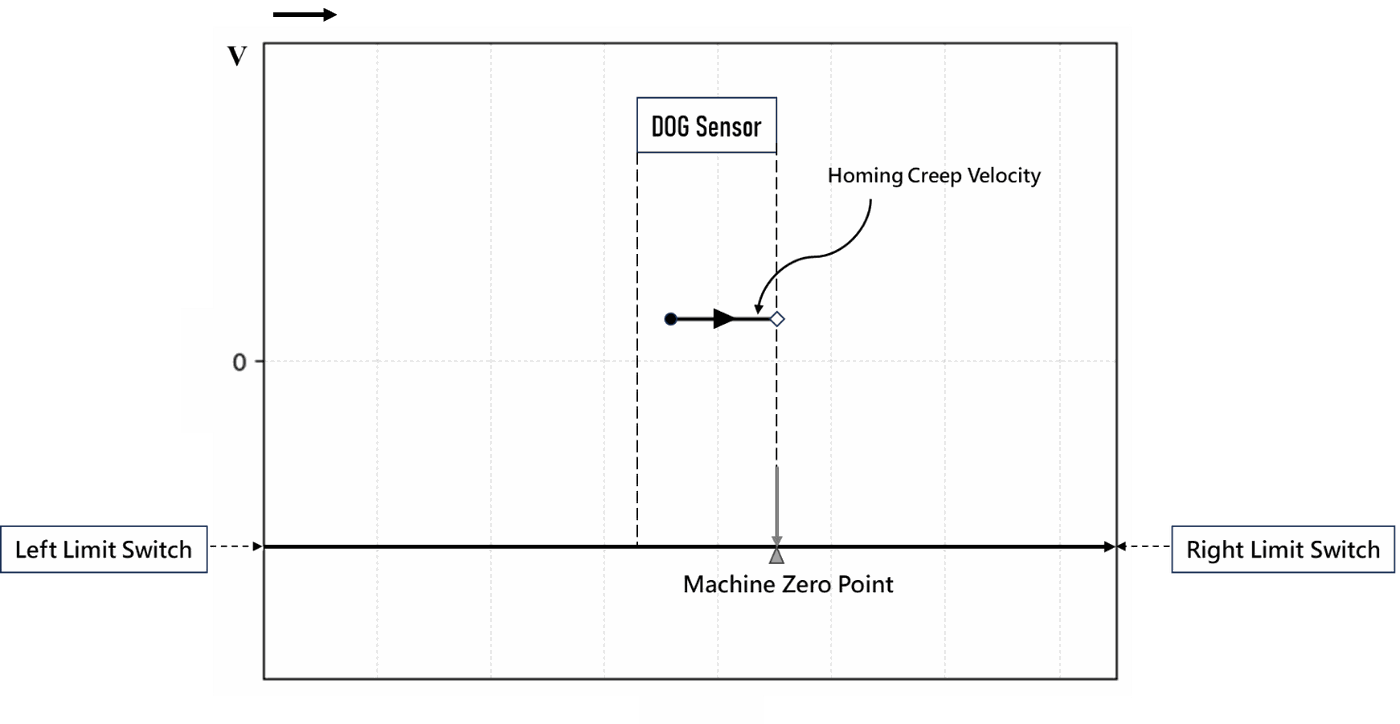
Action Description
The zero starting point is within the DOG sensor.
a. Move to the right limit direction at the Homing Creep Velocity.
b. The moment the signal is sensed away from Zero, this point is the Machine Zero Position.
10-2 Mode 101: Backward-Falling Trigger
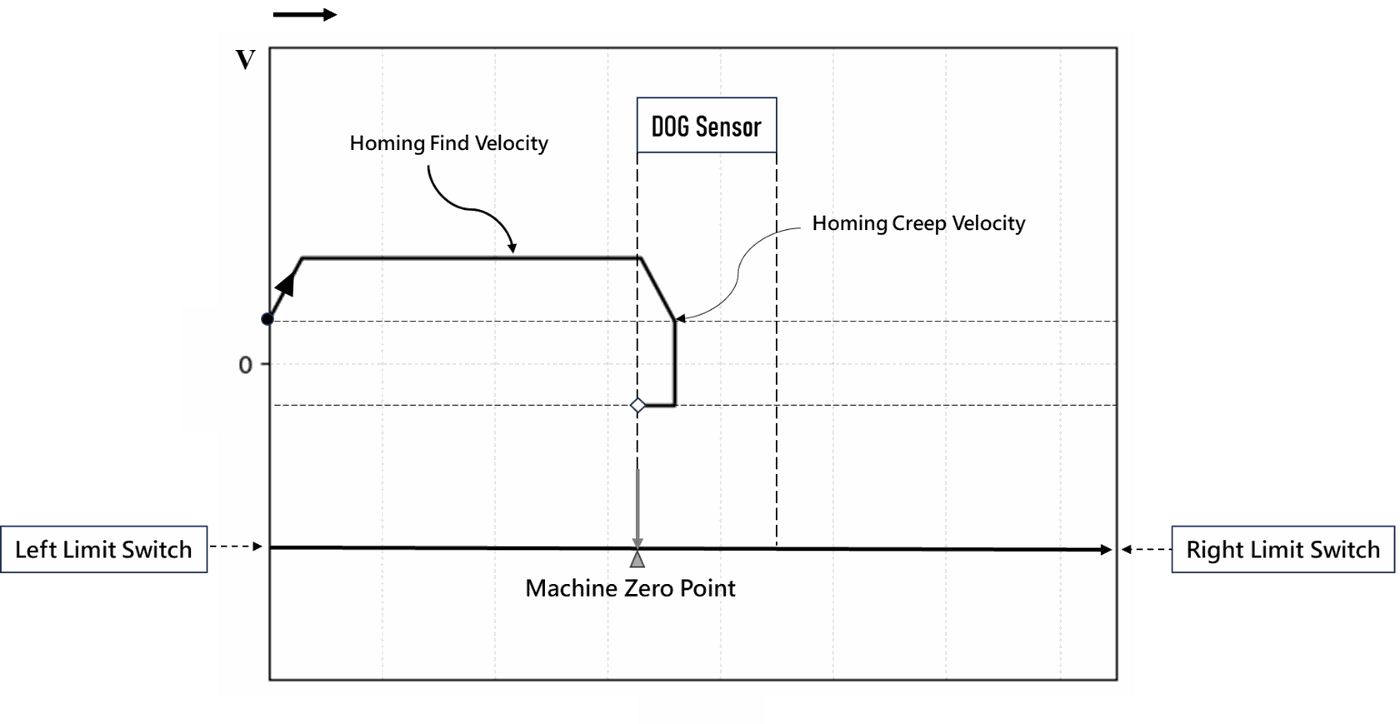
Action Description
The zero starting point is located to the left of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
c. The moment the signal is sensed away from Zero, this point is the Machine Zero Position.
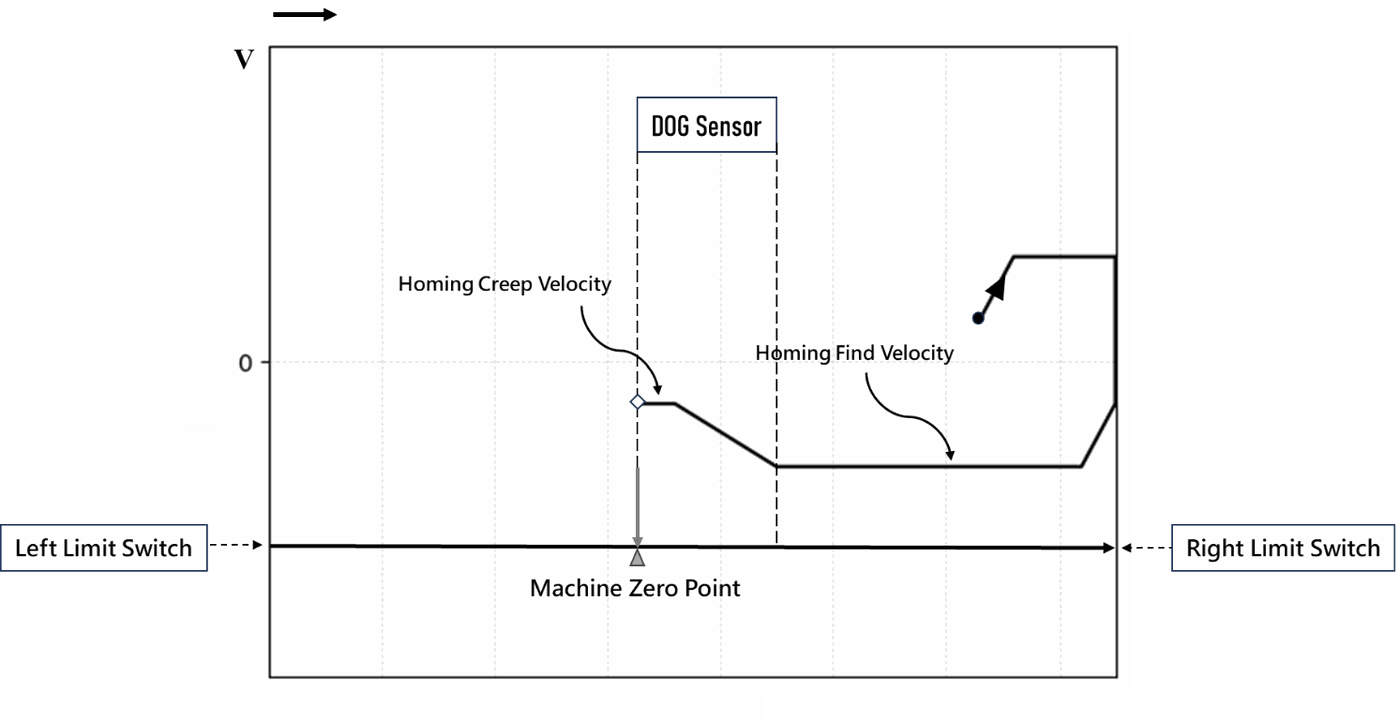
Action Description
The zero starting point is located to the right of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
d. The moment the signal is sensed away from Zero, this point is the Machine Zero Position.
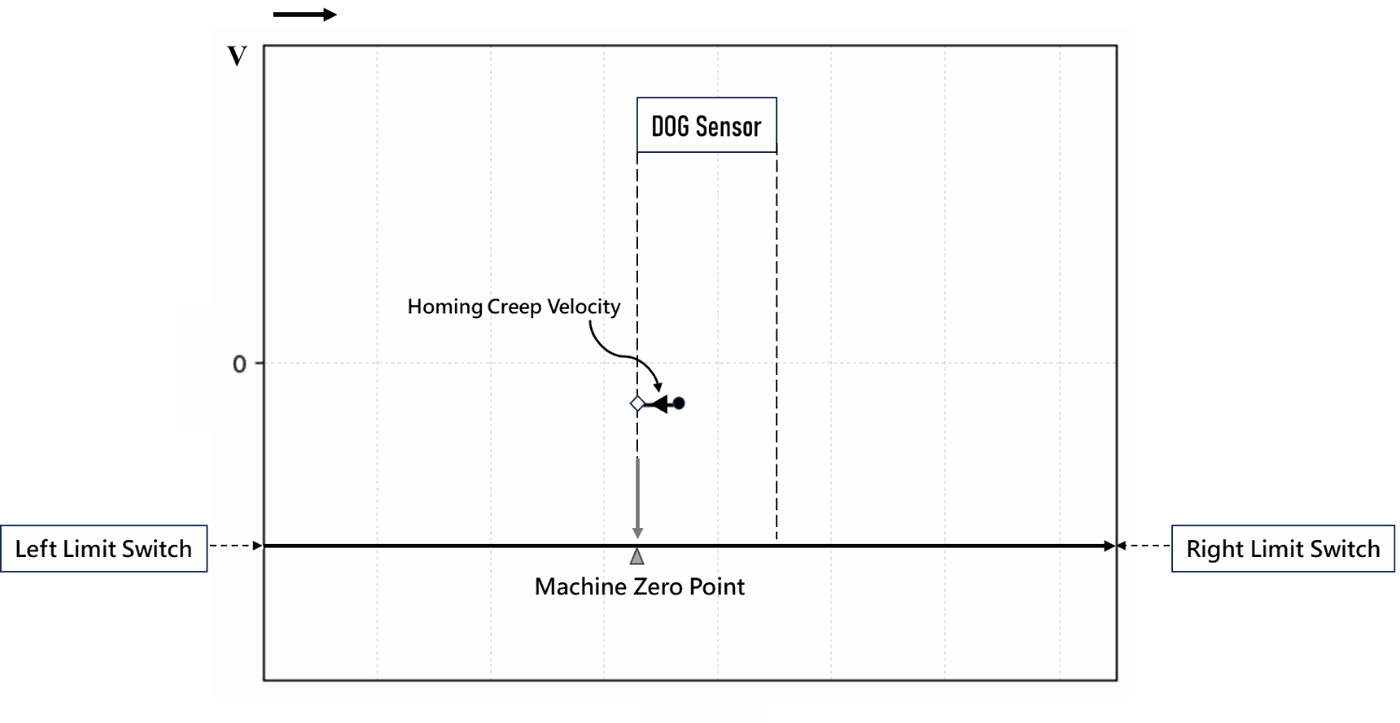
Action Description
The zero starting point is within the DOG sensor.
a. Move to the left limit direction at the Homing Creep Velocity.
b. The moment the signal is sensed away from Zero, this point is the Machine Zero Position.
10-3 Mode 102: Z Signal-Forward-Rising Trigger
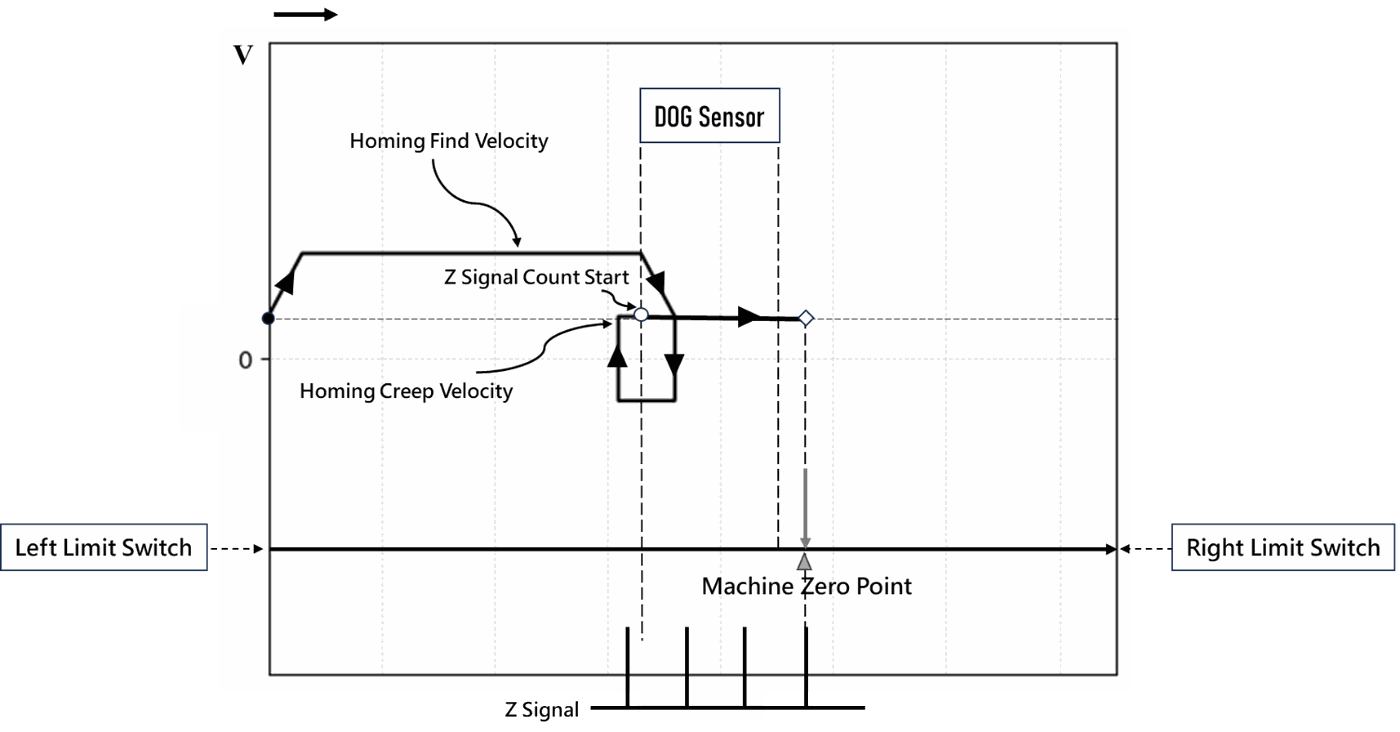
Action Description
The zero starting point is located to the left of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
c. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
d. When the signal is sensed away from Zero, start counting the Z-phase signal
e. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
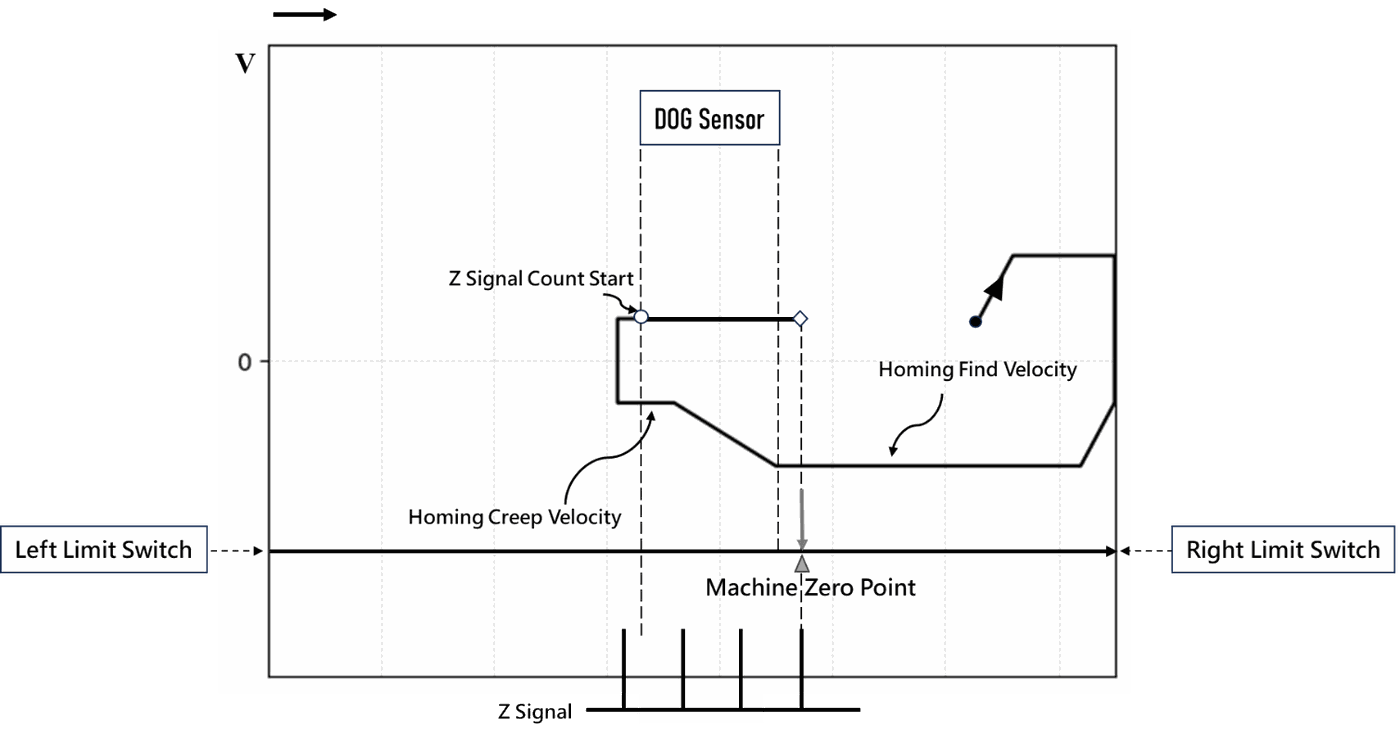
Action Description
The zero starting point is located to the right of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
d. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
e. When the signal is sensed away from Zero, start counting the Z-phase signal
f. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
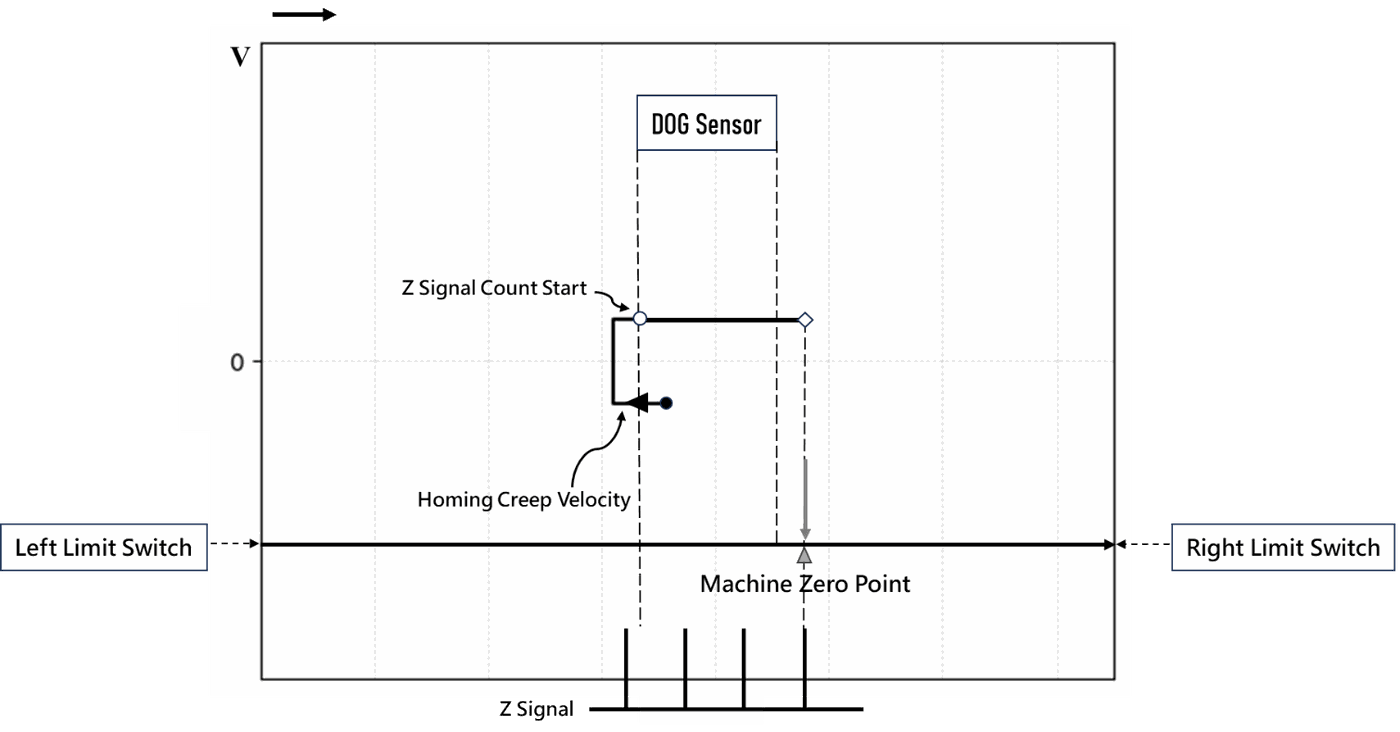
Action Description
The zero starting point is within the DOG sensor. Homing Z Count = 3.
a. Move to the left limit direction at the Homing Creep Velocity.
b. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
d. When the signal is sensed away from Zero, start counting the Z-phase signal
e. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
10-4 Mode 103: Z Signal-Forward-Falling Trigger
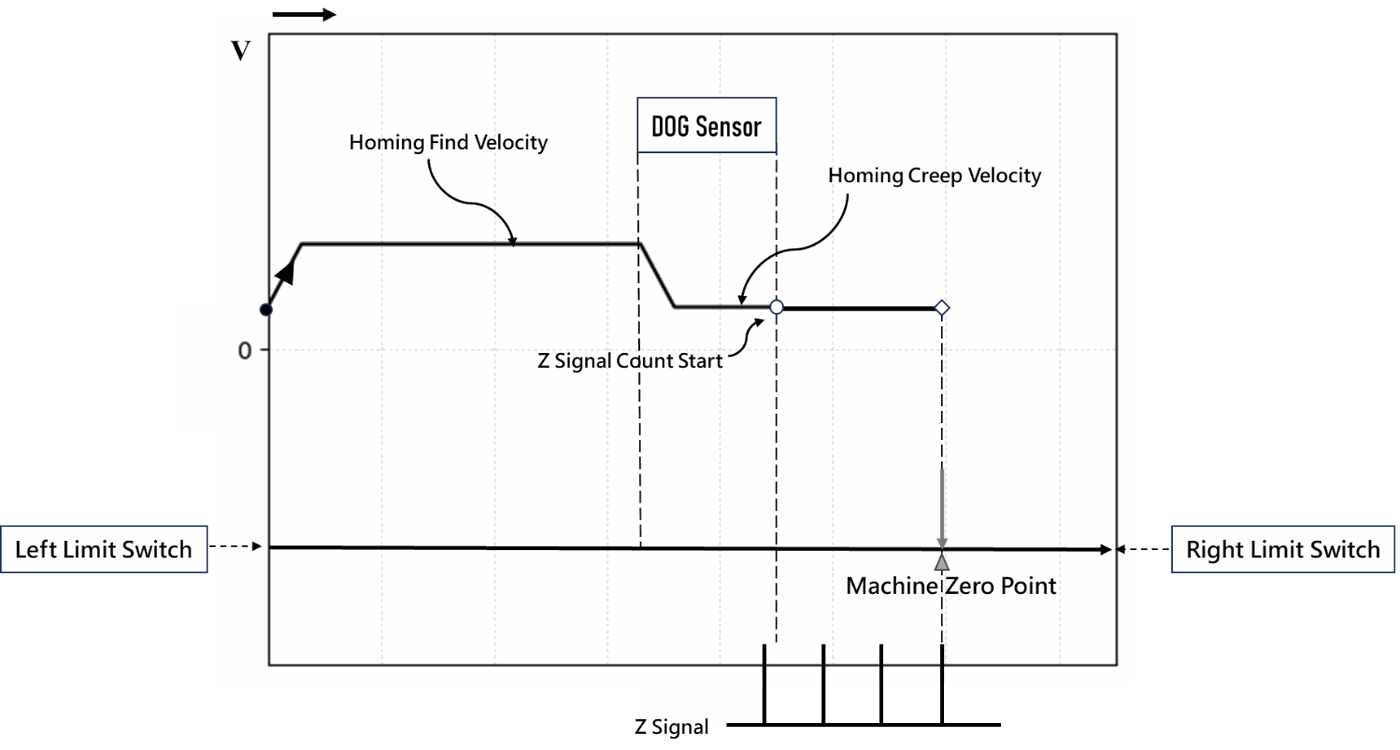
Action Description
The zero starting point is located to the left of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
c. When the signal is sensed away from Zero, start counting the Z-phase signal
d. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
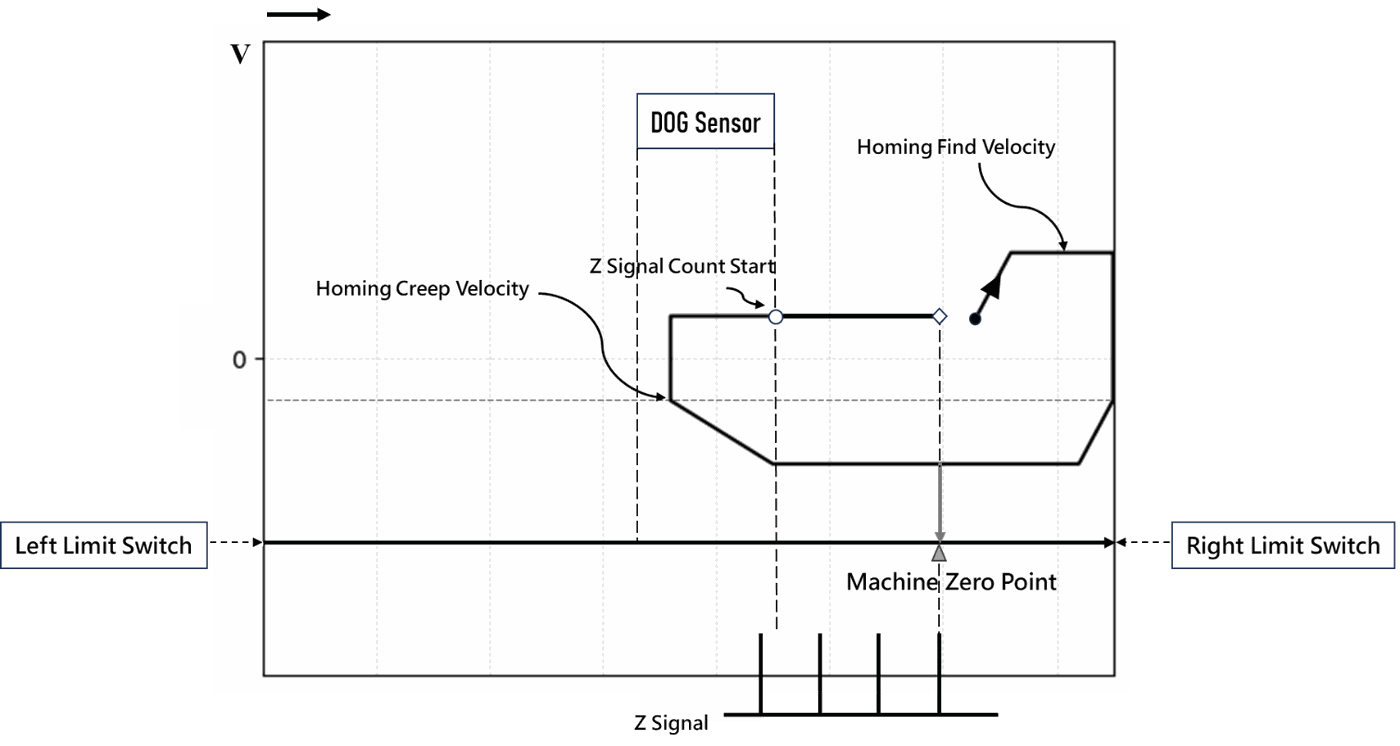
Action Description
The zero starting point is located to the right of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
d. When the signal is sensed away from Zero, start counting the Z-phase signal
e. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
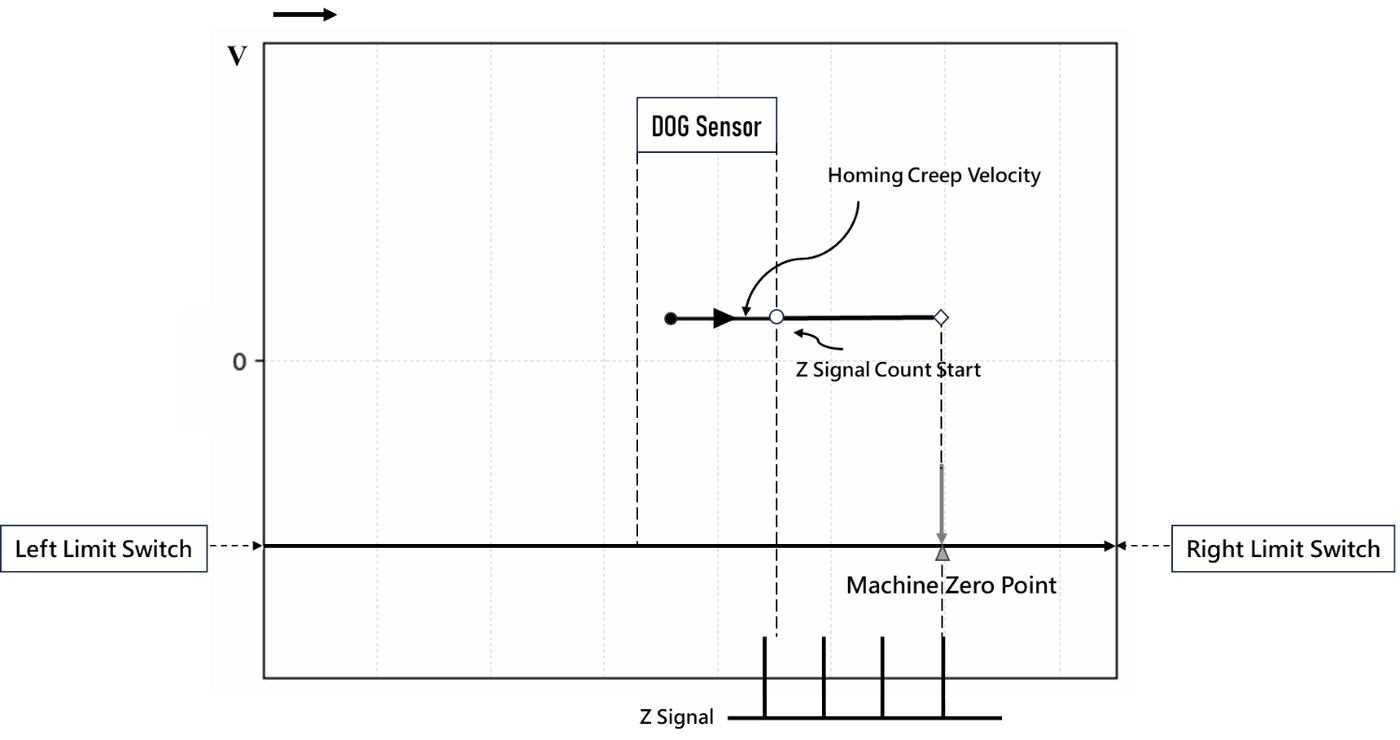
Action Description
The zero starting point is within the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Creep Velocity.
b. When the signal is sensed away from Zero, start counting the Z-phase signal
c. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
10-5 Mode 104: Forward-Rising Trigger
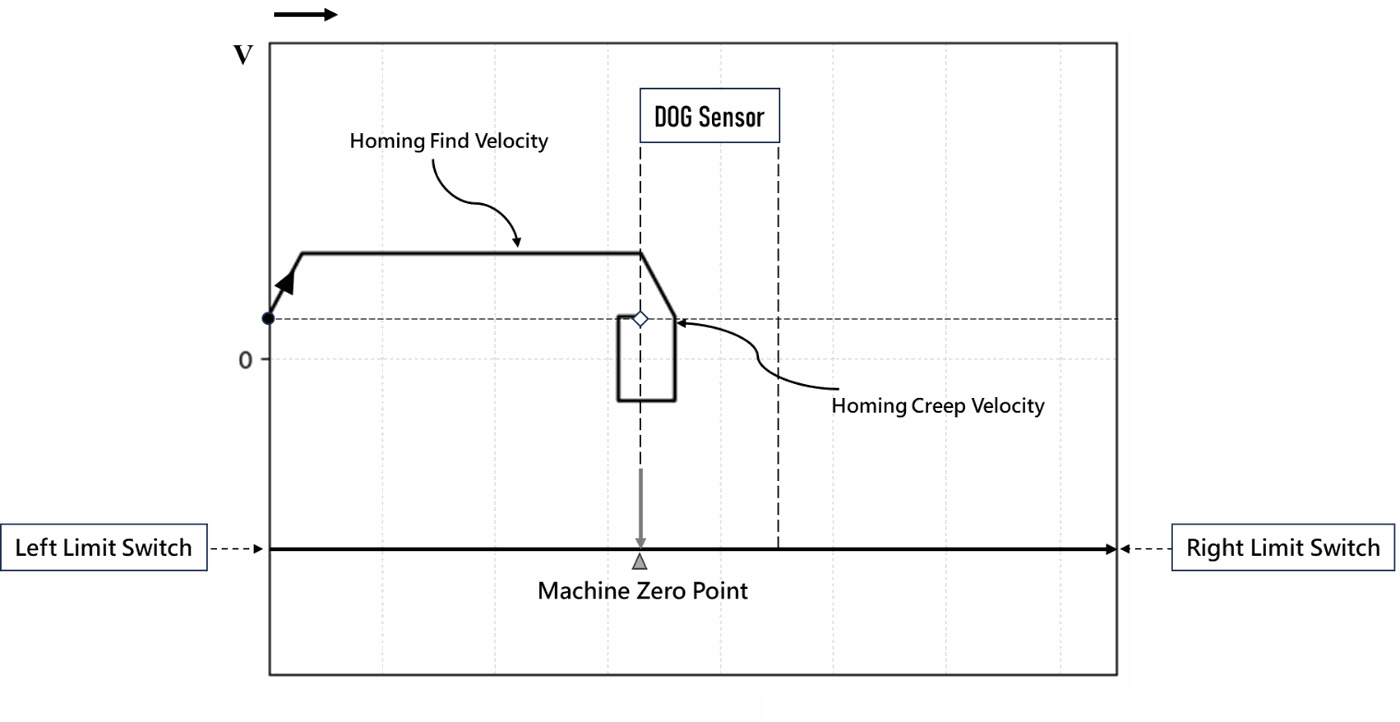
Action Description
The zero starting point is located to the left of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
c. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
d. The moment the signal is sensed at Zero, this point is the Machine Zero Position.
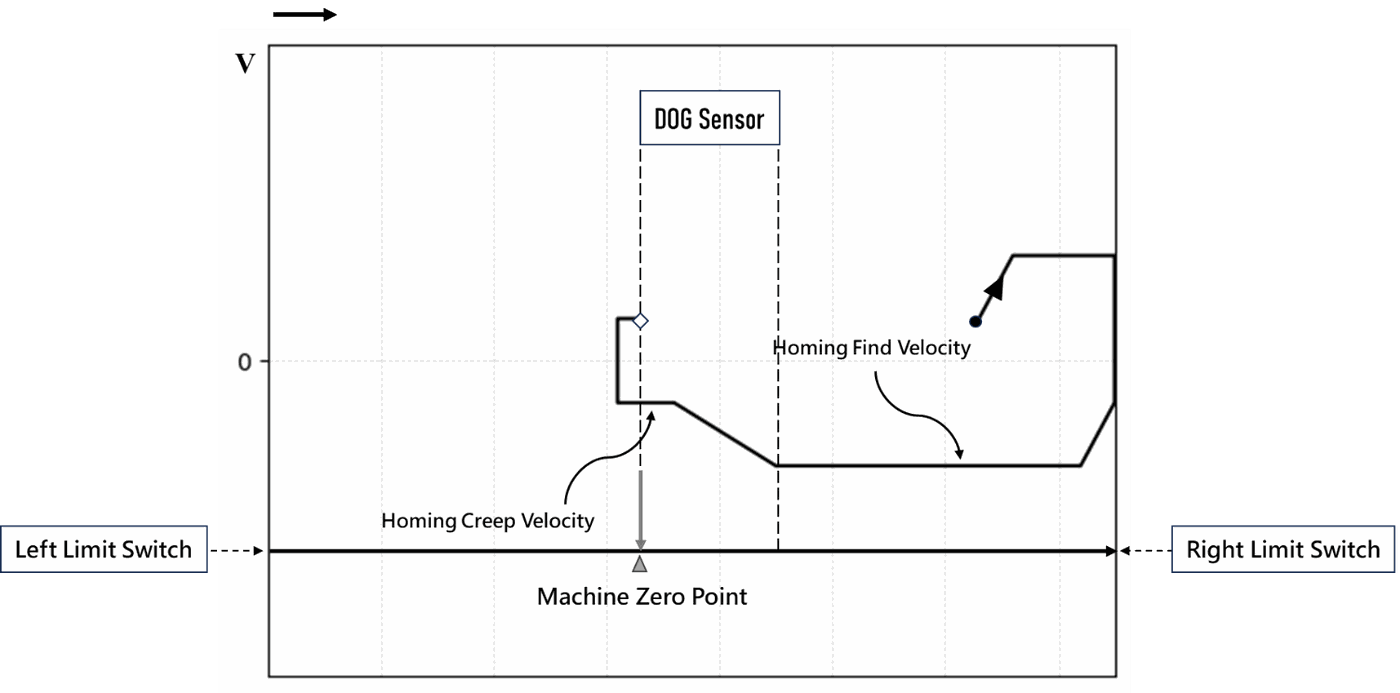
Action Description
The zero starting point is located to the right of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
d. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
e. The moment the signal is sensed at Zero, this point is the Machine Zero Position.
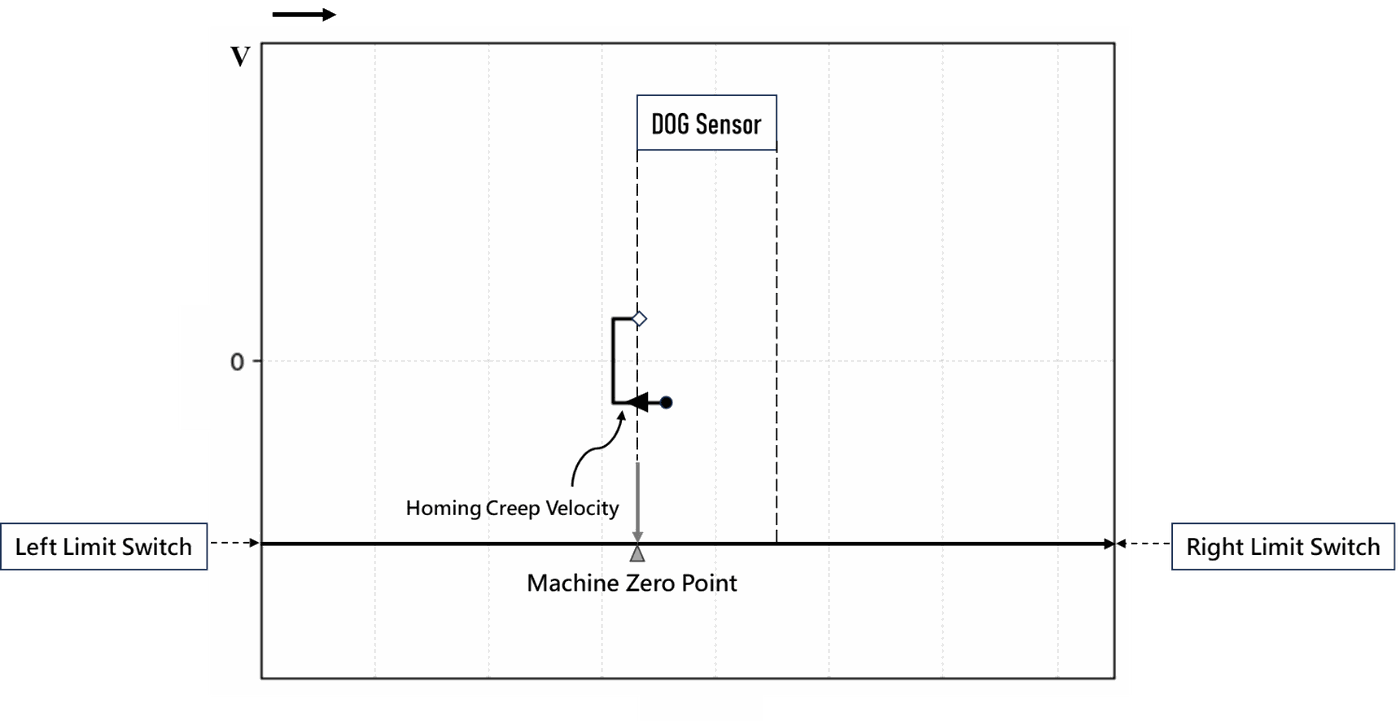
Action Description
The zero starting point is within the DOG sensor.
a. Move to the left limit direction at the Homing Creep Velocity.
b. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
c. The moment the signal is sensed at Zero, this point is the Machine Zero Position.
10-6 Mode 105: Backward-Rising Trigger
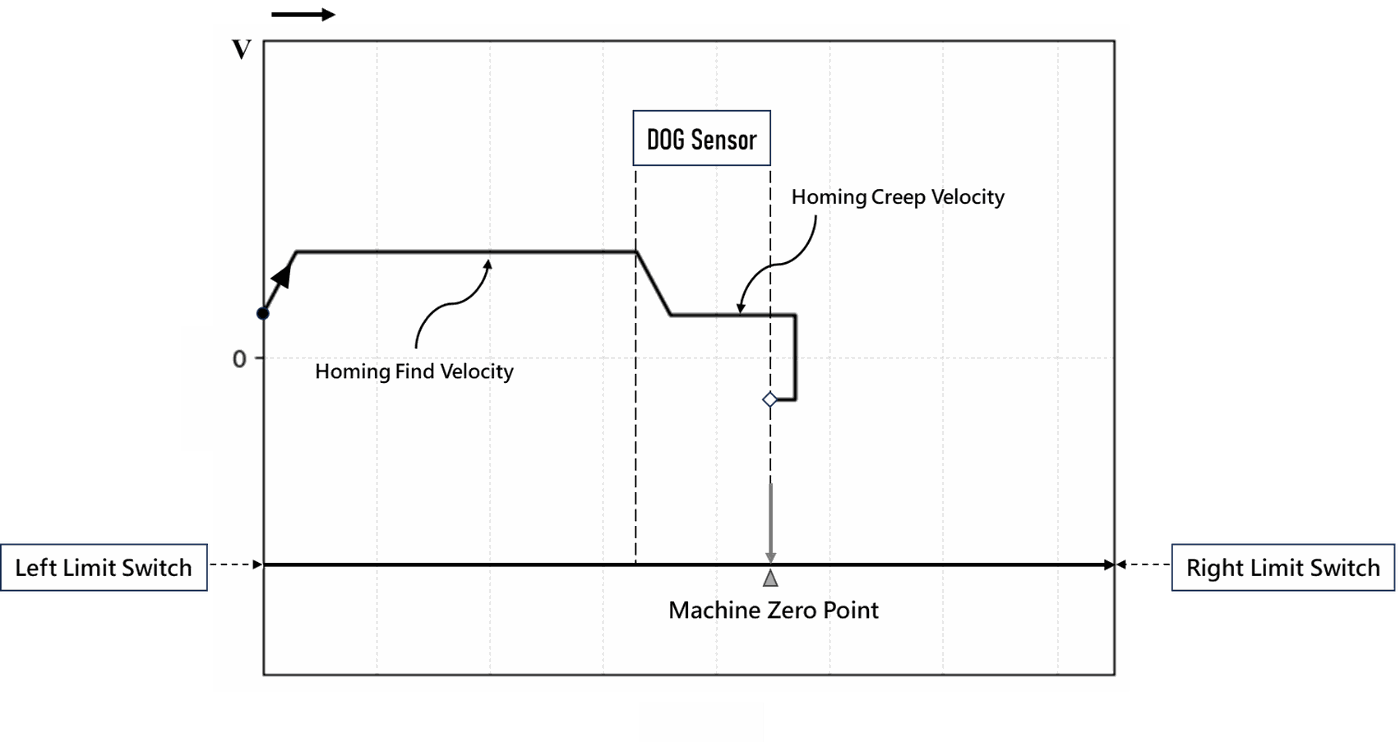
Action Description
The zero starting point is located to the left of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
c. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
d. The moment the signal is sensed at Zero, this point is the Machine Zero Position.
Action Description
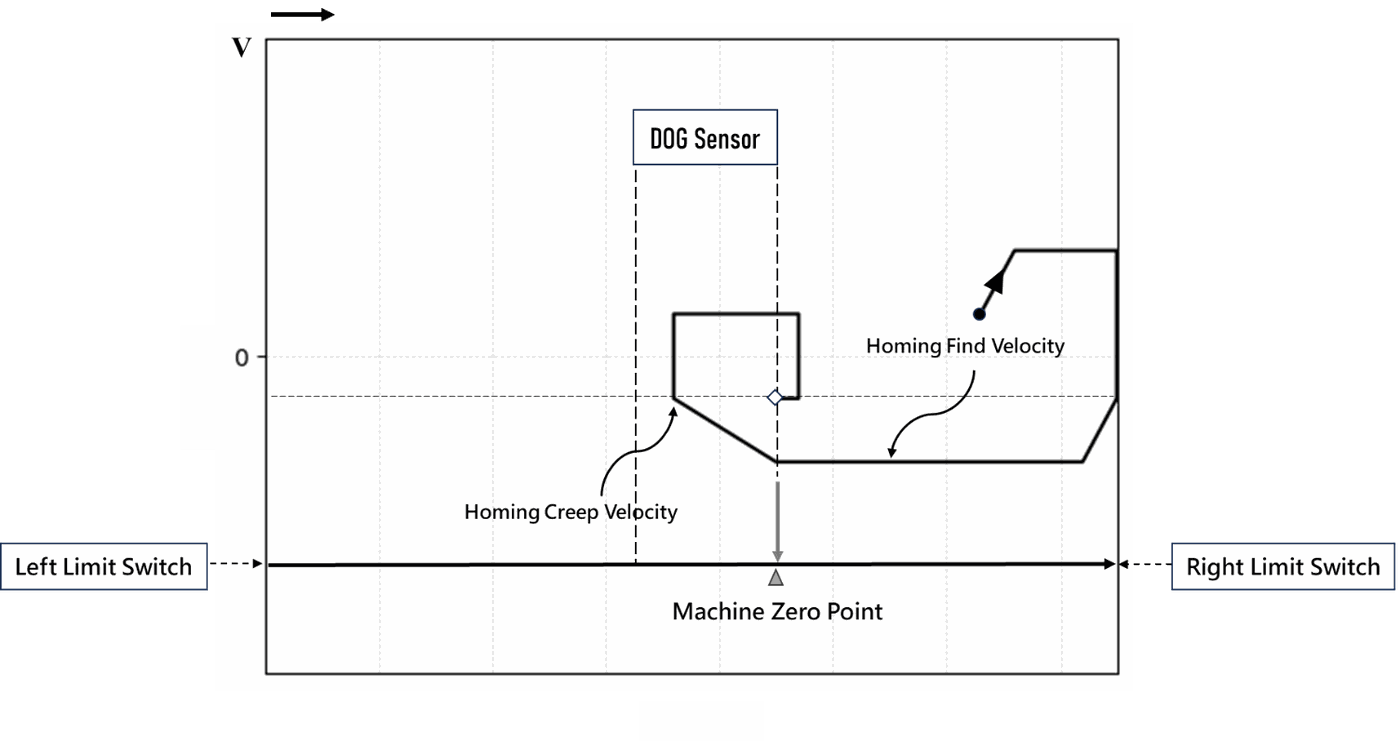
The zero starting point is located to the right of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
d. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
e. The moment the signal is sensed at Zero, this point is the Machine Zero Position.
Action Description
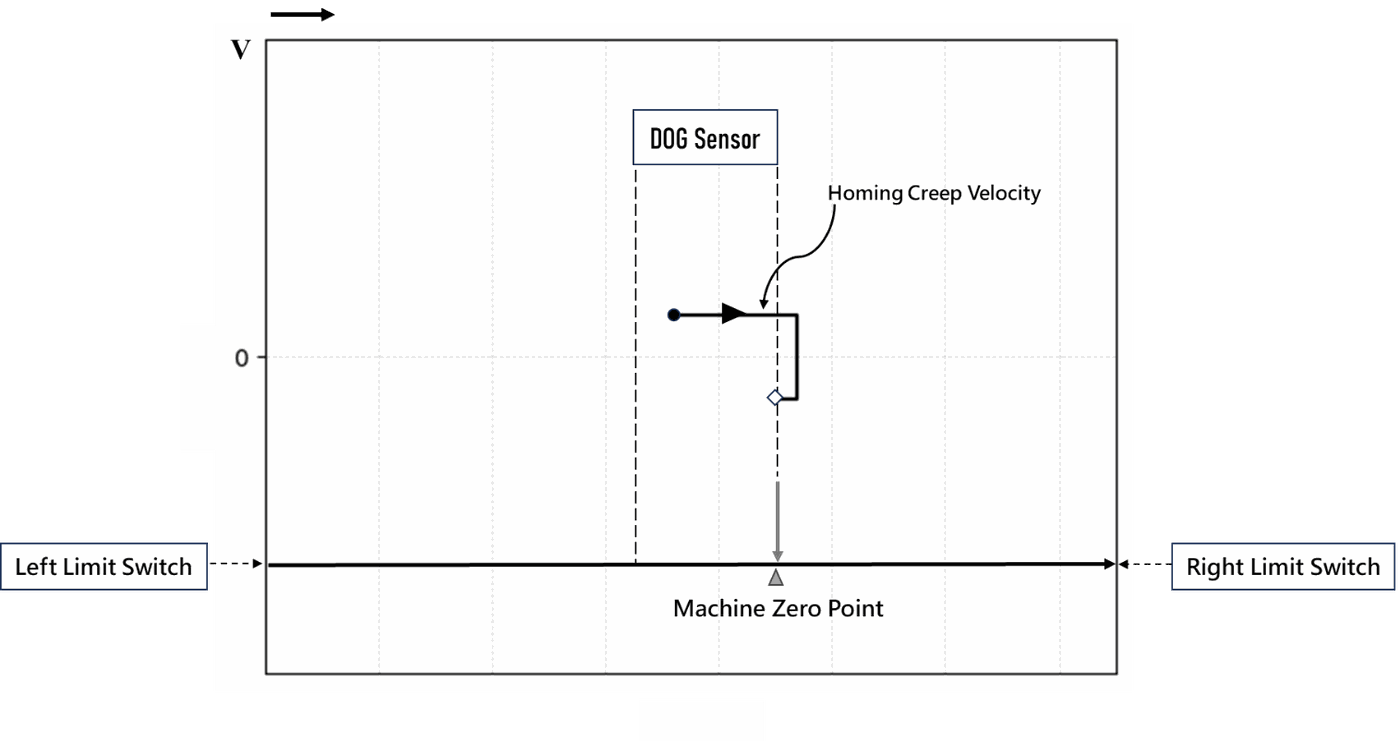
The zero starting point is within the DOG sensor.
a. Move to the right limit direction at the Homing Creep Velocity.
b. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
c. The moment the signal is sensed at Zero, this point is the Machine Zero Position.
10-7 Mode 106: Z Signal-Backward-Rising Trigger
Action Description
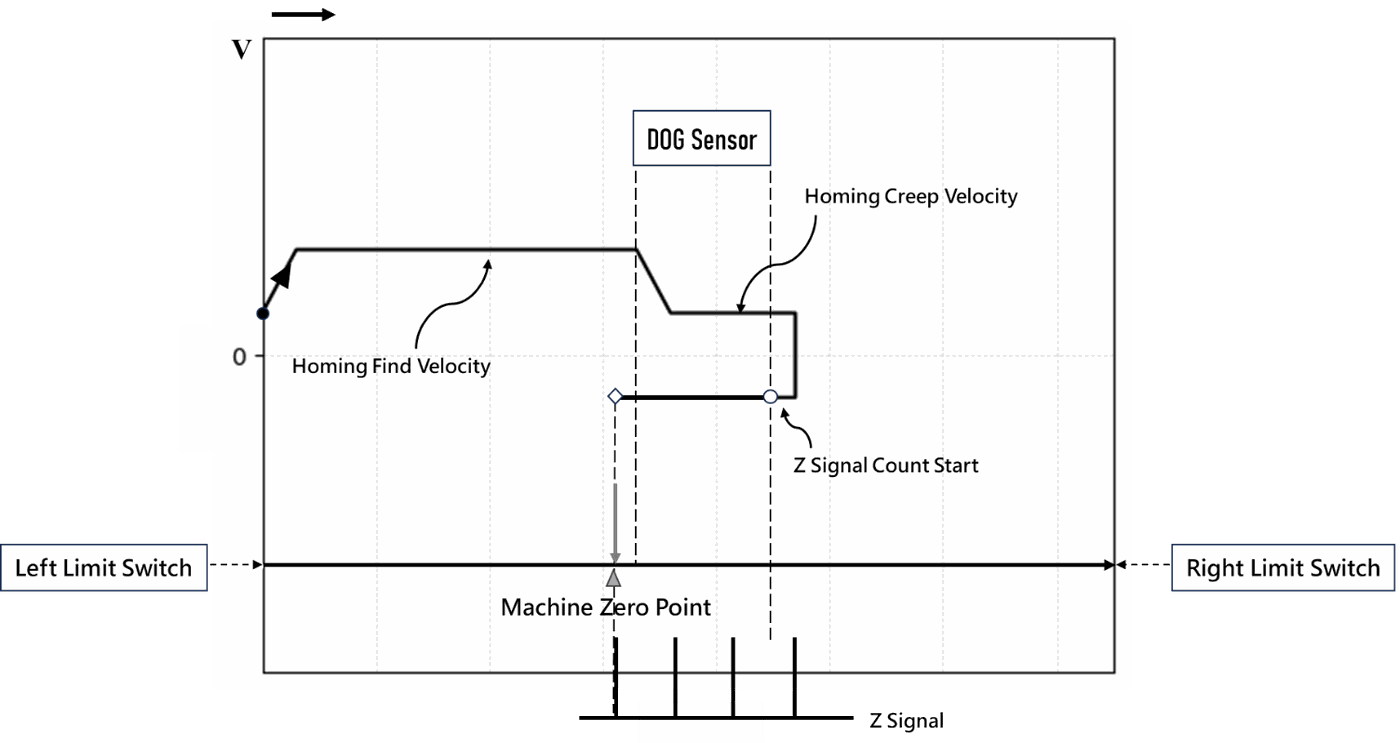
The zero starting point is located to the left of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
c. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
d. When the signal is sensed away from Zero, start counting the Z-phase signal
e. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
Action Description
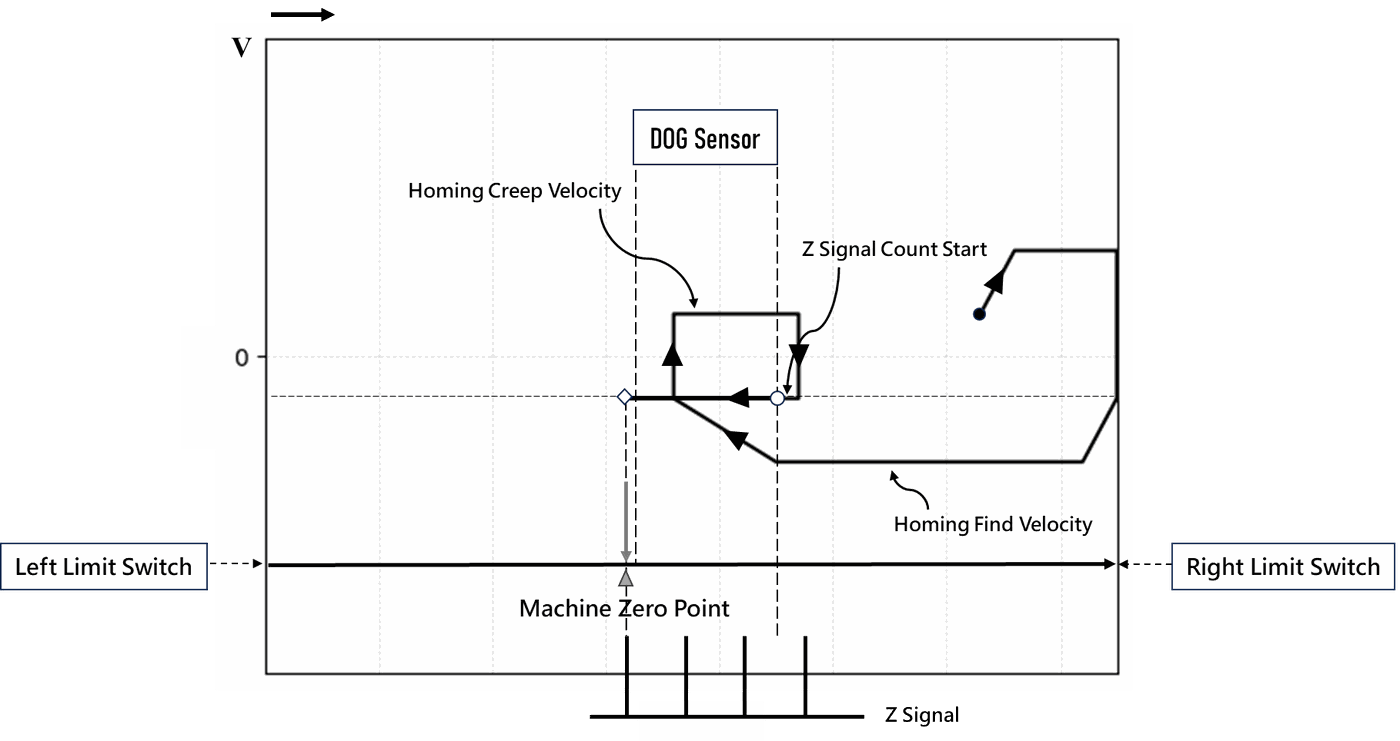
The zero starting point is located to the right of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
d. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
e. When the signal is sensed away from Zero, start counting the Z-phase signal
f. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
Action Description
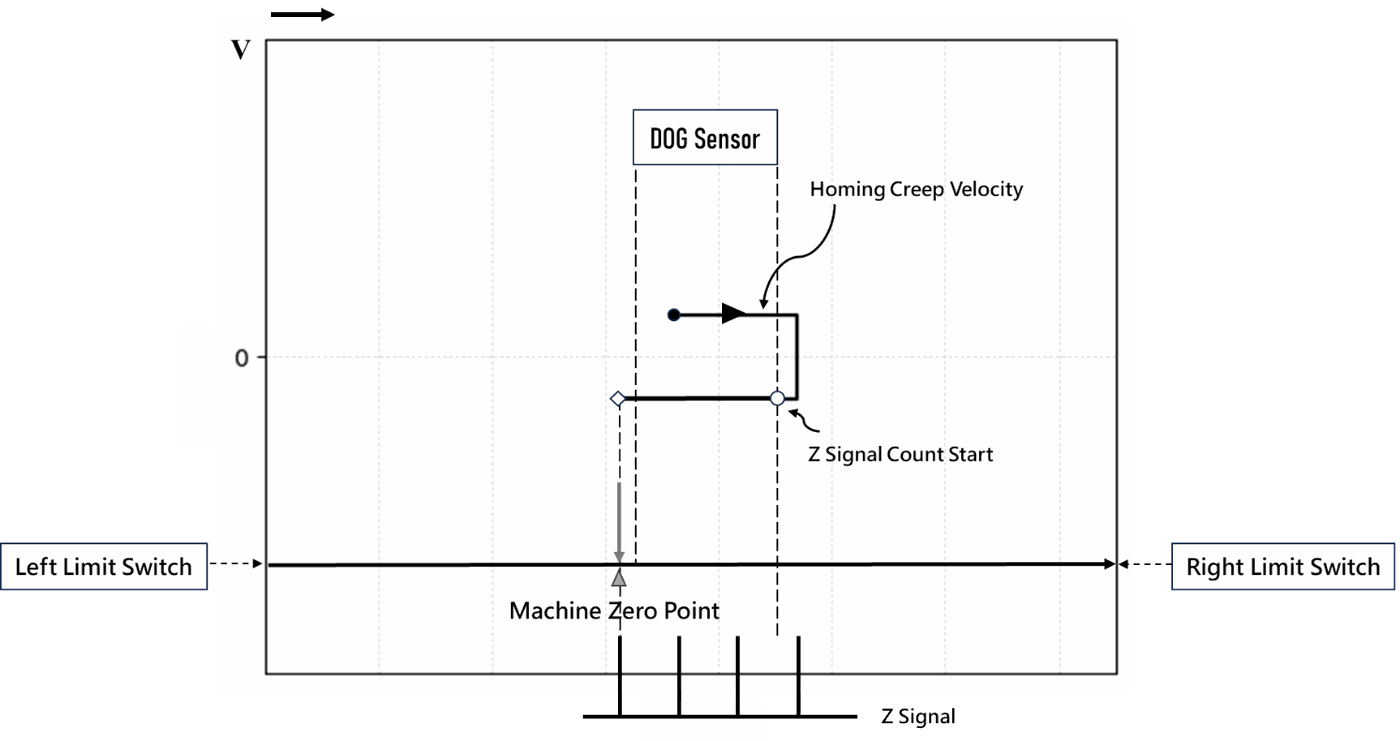
The zero starting point is within the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Creep Velocity.
b. When departing from Zero sensing signal, reverse search for the Zero sensing signal at the Homing Creep Velocity.
c. When the signal is sensed away from Zero, start counting the Z-phase signal
d. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
10-8 Mode 107: Z Signal-Backward-Falling Trigger
Action Description
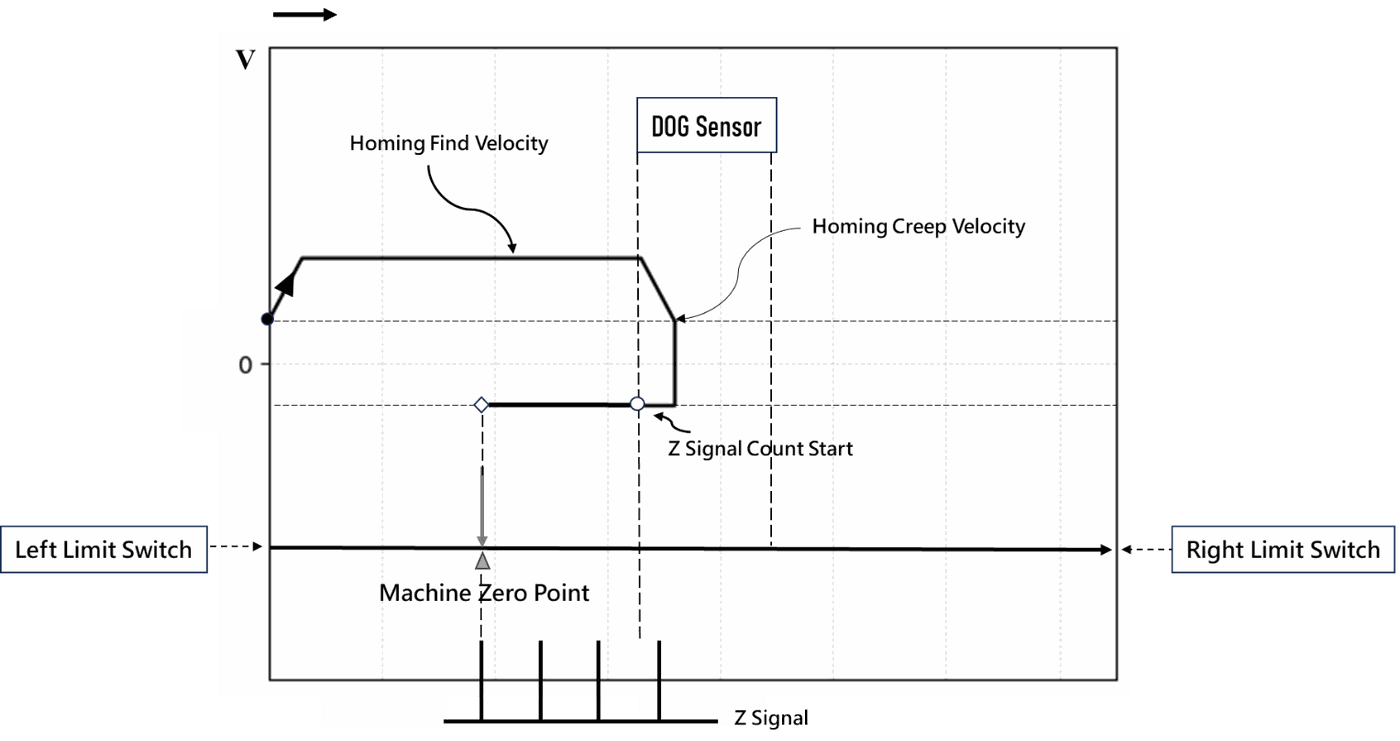
The zero starting point is located to the left of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and then move forward reversely.
c. When the signal is sensed away from Zero, start counting the Z-phase signal
d. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
Action Description
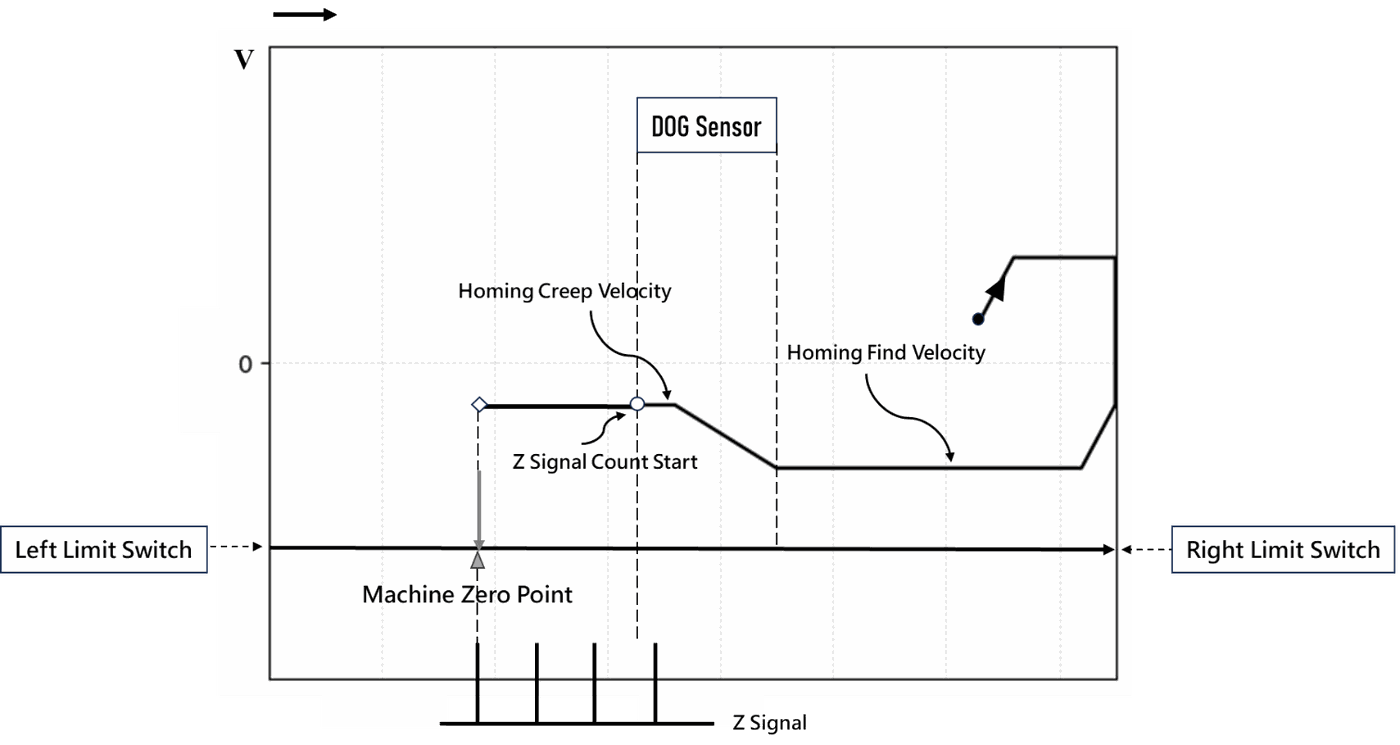
The zero starting point is located to the right of the DOG sensor. Homing Z Count = 3.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the right limit, move in the opposite direction towards the left limit.
c. When encountering the Zero sensing signal, the speed decreases to the Homing Creep Velocity and continue to move forward.
d. When the signal is sensed away from Zero, start counting the Z-phase signal
e. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
Action Description
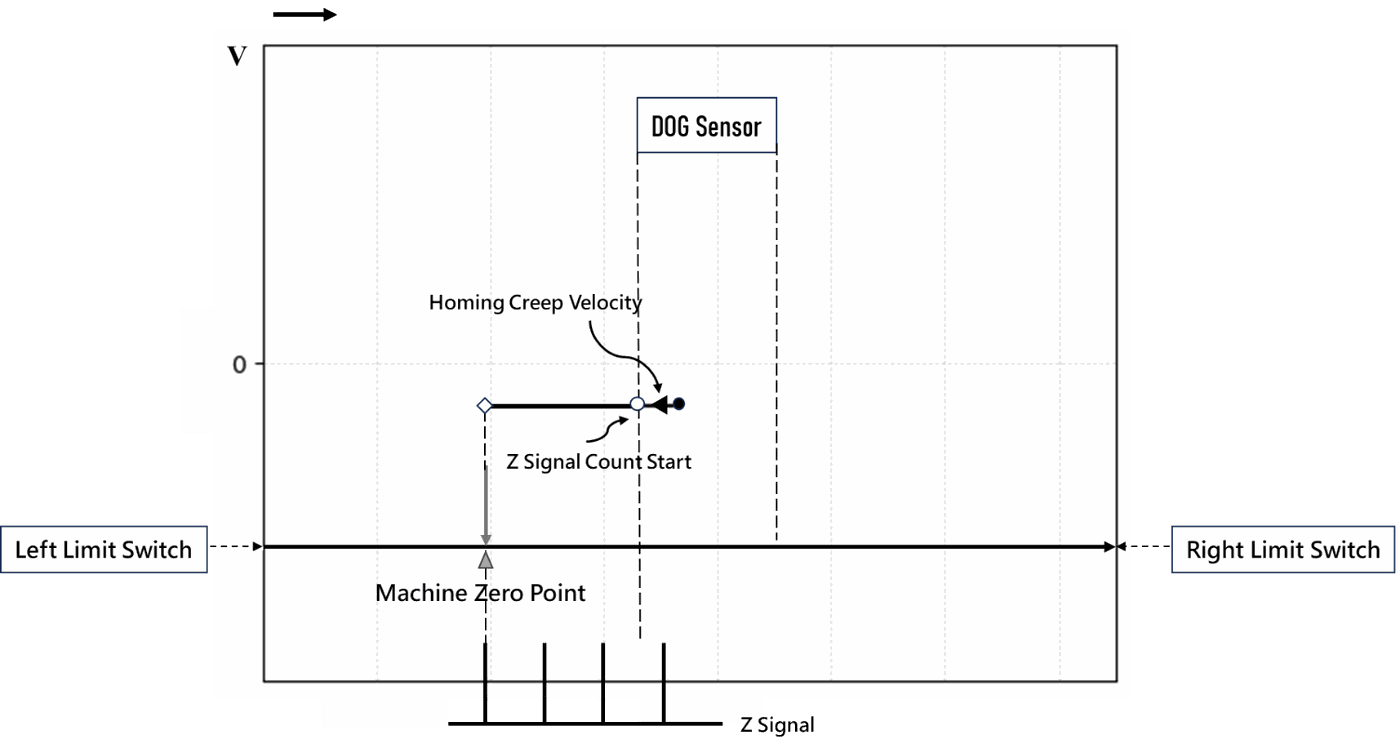
The zero starting point is within the DOG sensor. Homing Z Count = 3.
a. Move to the left limit direction at the Homing Creep Velocity.
b. When the signal is sensed away from Zero, start counting the Z-phase signal
c. When the count value of the Z-phase signal is equal to the set value of Homing Z Count, this point is the Machine Zero Position.
10-9 The Situation of Insufficient Deceleration.
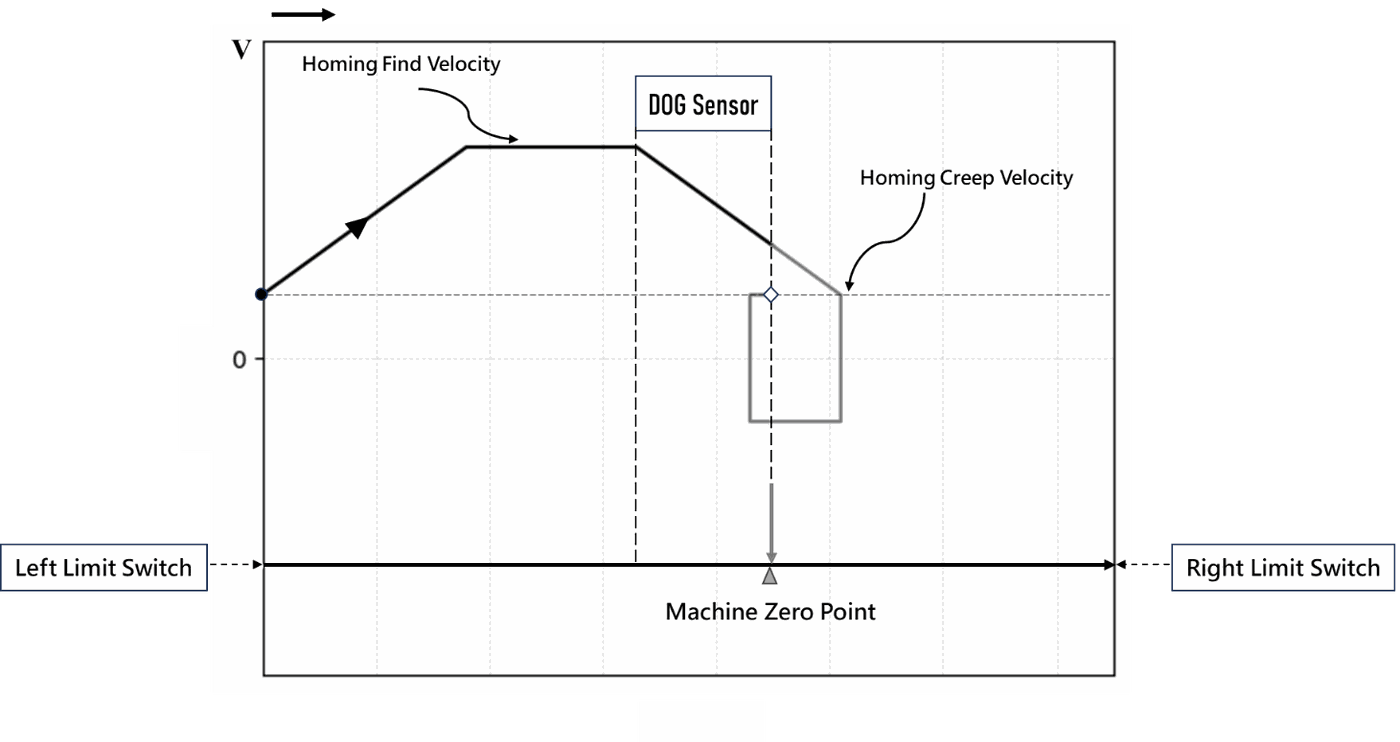
DOG Sensor detects a distance that is too short or insufficient deceleration, which may result in the speed not decreasing to the Homing Creep Velocity before leaving the Zero sensing signal. This means that the Homing may not be completed at this point.
Action Description
As an example, using the Forward-Falling Trigger mode.
The zero starting point is located to the left of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, decelerate at the Homing Deceleration.
c. When leaving the Zero sensing signal, the speed has not decreased to the Homing Creep Velocity.
d. The gray line segment indicates the compensation mechanism, continuing to reverse after reducing to the Homing Creep Velocity.
e. When encountering the Zero sensing signal, moving forward reversely.
f. The moment the signal is sensed away from Zero, this point is the Machine Zero Position.
Action Description
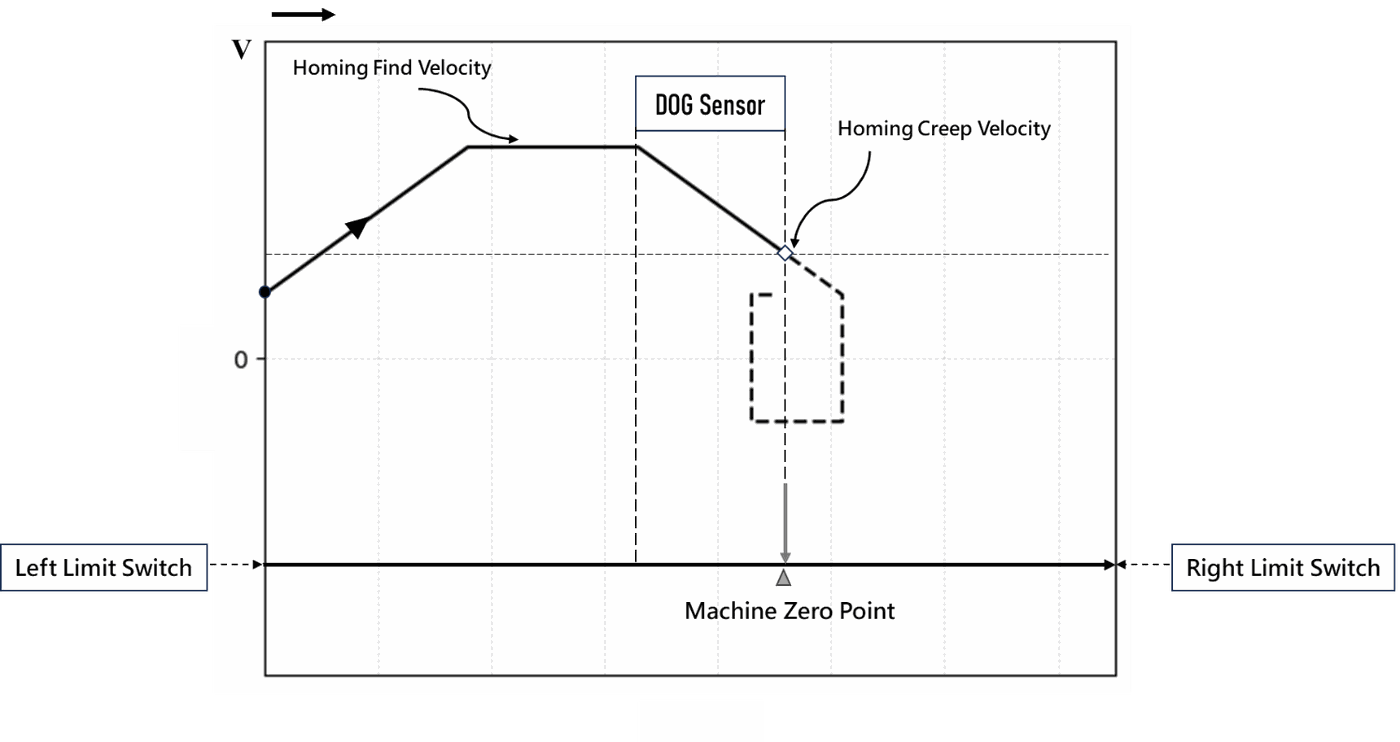
If user wish to skip steps d~f in the previous diagram, activate special register M10629 (High speed homing mode ON)
The zero starting point is located to the left of the DOG sensor.
a. Move to the right limit direction at the Homing Find Velocity.
b. When encountering the Zero sensing signal, decelerate at the Homing Deceleration.
c. The moment the signal is sensed away from Zero, stop at the current speed to complete the Homing, this point is the Machine Zero Position.
d. The dashed line represents the path of the gray line segment in the previous diagram. At this point, the Homing has been completed, so this path is not executed.
10-10 Description of HOME Return Related Parameters
- HOME return
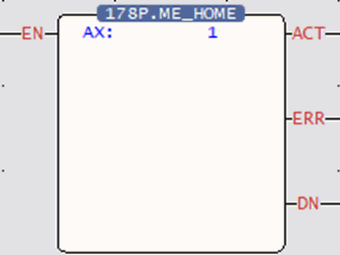 Definition: Executing the HOME return
- Fun178P. MFHome
EN = 1: Rising edge triggers HOME return
ACT = 1: HOME return is running
ERR = 1: HOME return error
DN = HOME return is done
- Internal Parameters
AX: Axis No.
- Special Register
Axis 1: HOME return is running – M10621
Axis 1: HOME return is done – M10622
- HOME return
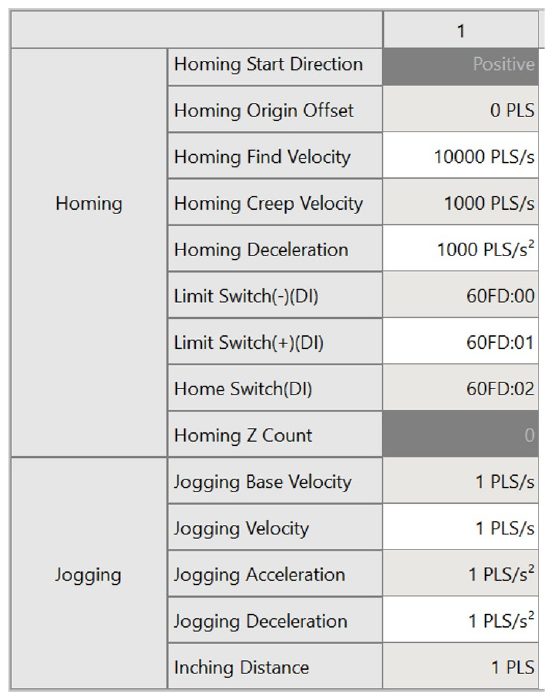
- Source of return
From PLC: PLC receives HOME/Forward Limit/Backward Limit signals
From Servo Driver: Servo Driver receives HOME/Forward Limit/ Backward Limit signals - Homing Start Direction: Forward/Backward
- Homing Origin Offset: The offsetting quantity for compensating the HOME return and positioning
- Homing Find Velocity: Search the HOME speed
- Homing Creep Velocity: Reduce to creep speed after touching the HOME
- Homing Deceleration: The deceleration required for reducing the reset crawl speed after touching the HOME
- Limit Switch (+)
- Limit Switch (-)
- HOME Switch
- Homing Z Count
- Source of Homing Z Count
Tip: press ← → to switch chapters, Ctrl+K to search